# 3D-Printed Automatic Weather Station (3D-PAWS)

The 3D-PAWS Manual provides guidance for building, deploying, and operating 3D-Printed Automatic Weather Stations using modular hardware and open-source electronics.

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FNkIHgTx48Vi1MQ0elTri%2FScreenshot%202025-10-24%20at%201.48.48%E2%80%AFPM.png?alt=media&amp;token=c2ea7975-a1b4-46ac-9f39-543905a7de1e" alt="3D-PAWS station showing a typical configuration with core meteorological instruments and modular components" width="375"><figcaption><p>3D-PAWS station showing a typical configuration with core meteorological instruments and modular components.</p></figcaption></figure>

***

#### Overview

3D-PAWS is an open, modular weather and environmental monitoring system that helps make reliable observations more accessible.

It combines 3D-printed parts, open-source electronics, and cloud-based data tools to create affordable and flexible observing systems. A typical station measures temperature, pressure, humidity, wind, and precipitation, with additional sensors available for applications such as water level, air quality, and soil monitoring.

Because the system is modular, stations can be configured to match local monitoring needs.

***

#### Role in Observation Networks

3D-PAWS is designed to complement, not replace, traditional weather observing systems.

It can expand observation networks in locations where conventional stations are difficult or expensive to install, providing additional observations for forecasting, modeling, research, and environmental decision-making.

***

#### Observing Practices and Standards

3D-PAWS follows widely accepted meteorological practices, including guidance from the *World Meteorological Organization* [***(WMO) Guide to Instruments and Methods of Observation (WMO-No. 8)***](https://community.wmo.int/site/knowledge-hub/programmes-and-initiatives/instruments-and-methods-of-observation-programme-imop/guide-instruments-and-methods-of-observation-wmo-no-8), particularly [**Volume I – Measurement of Meteorological Variables**](https://library.wmo.int/records/item/68695-guide-to-instruments-and-methods-of-observation?offset=3).

Good site selection, proper sensor exposure, and clear metadata documentation are emphasized throughout this manual to improve data quality.

Some 3D-PAWS measurements differ from traditional reference standards. For example, wind sensors are usually installed about **2 m above ground level**, rather than the 10 m height used in many operational networks.

***

#### Using This Manual

This manual follows the lifecycle of a 3D-PAWS station, from preparation and assembly through deployment, operation, and maintenance.

{% hint style="info" %}
Use the left-hand navigation menu to explore the manual. Use the **On this page** menu to navigate longer pages.
{% endhint %}

Main sections include:

* [**Getting Started**](/building-3d-paws/getting-started) – prepare to build and deploy a station
* [**Building 3D-PAWS**](/building-3d-paws) – assemble the station and instruments
* [**Setting Up the Data Logger**](/building-3d-paws/setting-up-the-data-logger) – configure hardware and communications
* [**Deploying 3D-PAWS**](/deploying-3d-paws) – select a site and install the station
* [**Accessing Data**](/accessing-the-data) – retrieve and view observations
* [**Station Maintenance and Operations**](/station-maintenance-and-operations) – maintain the station and troubleshoot problems
* [**Other 3D-PAWS Resources**](/other-3d-paws-resources) – find supporting documentation and resources

***

#### Where to Begin

New to 3D-PAWS? Start with: <a href="/building-3d-paws/getting-started" class="button primary">Getting Started</a>


# System Cost and Benefits

Cost estimates, deployment benefits, and project goals for low-cost 3D-PAWS stations.

### Overview

3D-PAWS is designed to provide reliable environmental monitoring at a fraction of the cost of many traditional commercial weather stations while remaining modular, locally manufacturable, and open-source.

A typical 3D-PAWS station costs:

**$325–$650 USD per station**

{% hint style="info" %}
Printer cost is not included. See the [**Bill of Materials**](https://docs.google.com/spreadsheets/d/10M0B0uvYnA0v-_q23aUk9Q1RNNS-oWH9inRZntQyyuM/edit?usp=sharing) spreadsheet for detailed pricing and supplier information.
{% endhint %}

***

#### What It Costs

**One-Time Infrastructure**

**3D Printer (Recommended: Bambu Lab P1S)**\
$700–$900

3D-PAWS components require a printer capable of reliably printing ASA with sufficient build volume. Any printer meeting these requirements may be used.

Because one printer can produce parts for many stations, the printer cost can be distributed across multiple builds.

***

**Per-Station Components**

**Printed Parts and Mechanical Hardware**\
$95–$145

**Standard Sensor Suite**\
$120–$180

The standard sensor suite includes:

* temperature and humidity
* pressure
* precipitation
* wind speed and direction

***

**Data Logger Options**

| Data Logger         | Estimated Cost | Notes                                                                                       |
| ------------------- | -------------: | ------------------------------------------------------------------------------------------- |
| **Particle Boron**  |      $140–$190 | Cellular; data plan not included                                                            |
| **WiFi Feather**    |       $75–$110 | Requires WiFi connectivity                                                                  |
| **LoRaWAN Feather** |       $90–$130 | Requires access to a compatible LoRaWAN gateway and the appropriate regional frequency band |

***

**Power Options**

| Power System               | Estimated Cost |
| -------------------------- | -------------: |
| **Commercial / USB Power** |        $25–$50 |
| **Solar + Battery System** |      $120–$200 |

***

#### Typical Station Configurations

| Configuration              | Estimated Cost |
| -------------------------- | -------------: |
| **WiFi + Grid Power**      |      $325–$450 |
| **LoRaWAN + Solar**        |      $400–$600 |
| **Cellular Boron + Solar** |      $475–$650 |

{% hint style="info" %}
Costs are estimates and may vary with suppliers, location, shipping, taxes, and station configuration. Optional sensors and communications infrastructure may add additional costs.
{% endhint %}

***

#### Benefits of 3D-PAWS

**Affordable Network Expansion**

Lower station costs can make it practical to increase station density and add observations in locations where conventional stations are difficult or expensive to install.

**Local Assembly and Manufacturing**

Stations can be assembled locally by meteorological services, schools, and partner organizations. Many mechanical components can also be reprinted locally when damaged, reducing dependence on specialized replacement parts.

**Modular and Adaptable**

Stations can be configured with different data loggers, communications methods, power systems, and sensors to match local monitoring needs and available infrastructure.

**Local Ownership and Sustainability**

Building, deploying, and maintaining stations locally helps develop technical capacity and supports long-term operation of observation networks.

**Open Design**

Open-source designs, documentation, and software allow organizations to build, modify, repair, and adapt the system for different environmental monitoring applications.

***

#### Supporting Observation Networks

3D-PAWS is designed to complement existing weather and environmental observing networks rather than replace higher-end reference instrumentation.

Lower-cost stations can help:

* increase observation density
* fill spatial gaps in existing networks
* extend monitoring into remote or underserved areas
* support forecasting and early warning
* provide environmental data for research and decision-making

By combining lower equipment costs with local manufacturing and maintenance, 3D-PAWS can make expansion of environmental observing networks more practical and sustainable.


# Testing and Data Validation

Historical 2016–2017 testing of 3D-PAWS sensors, with guidance for interpreting results and forthcoming independent validation.

### Overview

3D-PAWS has undergone laboratory testing, wind tunnel testing, and field comparison with calibrated reference instruments throughout its development.

The results presented on this page document an **early evaluation of the 3D-PAWS system conducted primarily from 2016–2017** at the NCAR Marshall Research Facility in Boulder, Colorado, and the NOAA Testbed Center in Sterling, Virginia.

These results provide an important baseline for the development of 3D-PAWS, but they should not be interpreted as a performance evaluation of the current system. Since this study was completed, 3D-PAWS hardware, sensors, 3D-printed components, electronics, software, and deployment practices have continued to evolve.

{% hint style="info" %}
**Updated evaluation:** A more recent independent comparison of 3D-PAWS observations with a reference weather station has been conducted through TSMS. Results will be added to this manual when the final WMO report is available.
{% endhint %}

***

#### Historical 2016–2017 Evaluation

The original 3D-PAWS meteorological sensors were evaluated through laboratory calibration, wind tunnel testing, and comparison with calibrated commercial reference instruments.

The results below document the sensors and configurations used during that evaluation period and provide a historical record of system performance.

{% hint style="warning" %}
Sensor models and station configurations have changed since this evaluation. The performance values below apply to the sensors and configurations tested during the 2016–2017 study and should not be assumed to represent all current 3D-PAWS configurations.
{% endhint %}

***

#### Laboratory and Wind Tunnel Testing

Before field evaluation, temperature, pressure, and relative humidity sensors were calibrated in a controlled environment. Laboratory results were within the manufacturers' specifications.

The 3D-PAWS tipping bucket rain gauge was tested using simulated rainfall rates from **0.1 to 30 mm/h**, with less than **5% error** during these tests.

The 3D-PAWS 3-cup anemometer and wind vane were tested and calibrated in a NOAA wind tunnel at the NOAA Testbed facility.

Testing included wind speeds up to **70 m/s**. The 3-cup anemometer performed well at these high wind speeds, and wind direction measurements remained consistent across the tested range.

***

#### Field Evaluation

Field evaluations were conducted at:

* **NCAR Marshall Research Facility** – Boulder, Colorado
* **NOAA Testbed Center** – Sterling, Virginia

3D-PAWS observations were compared with calibrated commercial reference instruments.

Reference observations were matched with 3D-PAWS observations at **1-minute resolution** to estimate measurement error.

Where possible, observations were also evaluated by:

* daytime and nighttime conditions
* warm and cold seasons
* environmental conditions that could affect sensor performance

The primary evaluation period was **June 2016 through March 2017**, although evaluation periods varied by sensor and data availability.

***

#### Reference Instruments

The following instruments were used as references during the field evaluation.

| Measurement           | NCAR Marshall Research Facility           | NOAA Testbed Center                                             |
| --------------------- | ----------------------------------------- | --------------------------------------------------------------- |
| **Temperature**       | Campbell Scientific 500 series sensor     | Technical Services Laboratory 1088 hygrothermometer             |
| **Pressure**          | Vaisala PTB101B                           | Coastal Environmental Systems PDB-1 precision digital barometer |
| **Relative Humidity** | Campbell Scientific 500 series sensor     | Technical Services Laboratory 1088 hygrothermometer             |
| **Wind Speed**        | R.M. Young 05108 anemometer               | Vaisala 425NWS ice-free wind sensor                             |
| **Wind Direction**    | R.M. Young 05108 anemometer               | Vaisala 425NWS ice-free wind sensor                             |
| **Precipitation**     | Geonor T-200 weighing precipitation gauge | OTT AWPAG weighing precipitation gauge                          |

***

#### Temperature

Temperature observations were evaluated at both test sites, with similar measurement performance.

Three temperature sensors were integrated into the 3D-PAWS configuration used during this evaluation:

* BMP180
* HTU21D
* MCP9808

All three sensors agreed well with the calibrated reference sensor over the observed temperature range of approximately **−25°C to 37°C**.

For the NCAR Marshall evaluation, the reported measurement error for all observations was:

**±0.57°C**

The error was slightly larger during daytime observations and lower at night. The original evaluation attributed this difference to solar heating of the radiation shield during the day.

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FWBCgkytOP1ejKFPvdpBt%2Fimage.png?alt=media&amp;token=2c8df223-ccdd-4750-af43-ea001fc10972" alt=""><figcaption></figcaption></figure>

**Figure 1.** Temperature sensor evaluation. From left to right: all observations, daytime observations, and nighttime observations.

***

#### Atmospheric Pressure

Barometric station pressure was evaluated at both test sites, with similar performance observed.

The **BMP180** pressure sensor was used in the 3D-PAWS configuration evaluated during this study.

For the NCAR Marshall evaluation from June 2016 through March 2017, the reported measurement error for all observations was:

**±0.49 hPa**

When separated by time of day:

* daytime: **±0.53 hPa**
* nighttime: **±0.37 hPa**

The original evaluation attributed the slightly larger daytime error to heating and greater daytime temperature variation.

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FoROen86CLPpuuGXMdAXZ%2Fimage.png?alt=media&amp;token=d283d915-dd53-46df-90cf-4d3900fabd1a" alt=""><figcaption></figcaption></figure>

**Figure 2.** Atmospheric pressure sensor evaluation. From left to right: all observations, daytime observations, and nighttime observations.

***

#### Relative Humidity

Relative humidity sensors were evaluated at both the NCAR Marshall Research Facility and NOAA Testbed Center, with similar behavior observed at both sites.

The reported mean measurement error was:

**±5.7% RH**

When separated by time of day:

* daytime: **±5.98% RH**
* nighttime: **±4.87% RH**

The evaluation found substantial scatter in the mid-humidity range of approximately **20–80% RH**, along with a low bias at very low (**<10%**) and very high (**>90%**) relative humidity.

Occasional anomalous behavior was also observed. The original evaluation suggested that condensation on either the 3D-PAWS or reference sensor may have contributed.

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FmbG3qLh4xxUhGtQ1UajU%2Fimage.png?alt=media&amp;token=d7fe3371-9f99-448b-a40c-ca7937389ab3" alt=""><figcaption></figcaption></figure>

**Figure 3.** Relative humidity sensor evaluation. From left to right: all observations, daytime observations, and nighttime observations.

***

#### Wind Speed and Direction

Wind speed and wind direction observations were compared with calibrated reference measurements.

The reported wind speed measurement error was:

**±0.87 m/s**

When separated by time of day:

* daytime: **±0.94 m/s**
* nighttime: **±0.79 m/s**

The 3D-PAWS wind measurements generally agreed with the predominant wind observed by the reference sensor.

The reported wind direction measurement error was less than: **±5°**

***

#### Precipitation

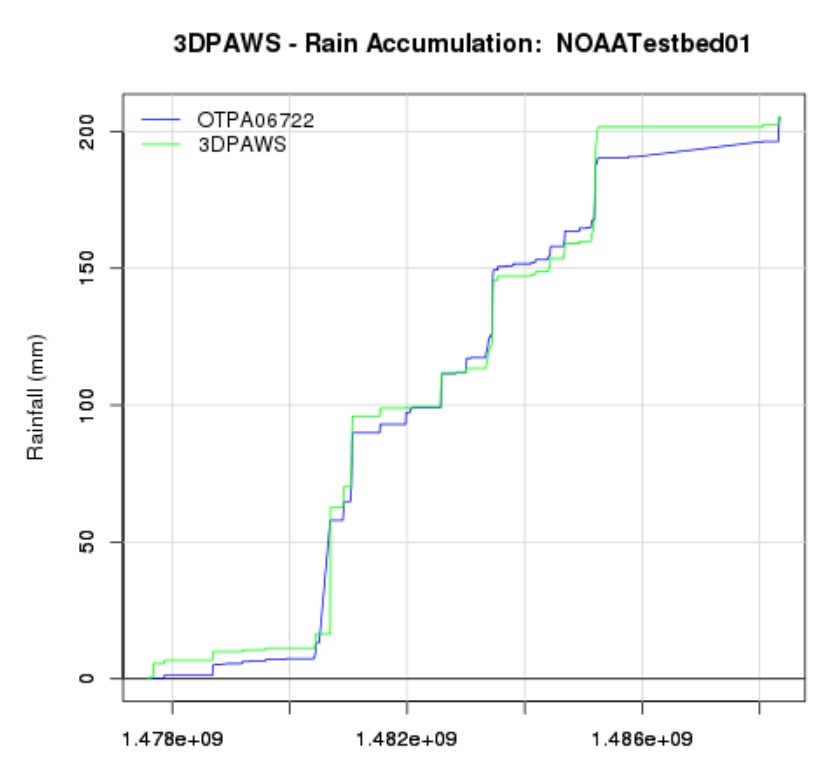
The 3D-PAWS tipping bucket rain gauge was compared with the NOAA Testbed weighing precipitation gauge from **October 2016 through March 2017**.

Approximately **200 mm of precipitation** was recorded during the evaluation period.

Total accumulation showed good agreement between the gauges. Small differences were observed during individual precipitation events, which the original evaluation attributed primarily to wind and precipitation-rate effects.

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FnViojlPOdA0vPNai65rG%2Fimage.png?alt=media&amp;token=3b86efb3-1a2b-4180-a743-68e4fa5ea611" alt=""><figcaption></figcaption></figure>

**Figure 4.** Rainfall accumulation observed by the 3D-PAWS tipping bucket rain gauge and NOAA weighing-gauge reference sensor.

***

#### 2016–2017 Evaluation Summary

The original evaluation concluded that the tested 3D-PAWS sensors generally compared well with calibrated reference instruments.

The following values were reported in the original evaluation summary:

| Measurement           | Resolution | Reported Performance |
| --------------------- | ---------: | -------------------: |
| **Temperature**       |      0.1°C |               ±0.4°C |
| **Pressure**          |    0.1 hPa |             ±0.4 hPa |
| **Relative Humidity** |         1% |                ±5.7% |
| **Wind Speed**        |    0.1 m/s |             ±0.8 m/s |
| **Wind Direction**    |         1° |                  ±5° |
| **Rainfall**          |     0.2 mm |                  10% |

{% hint style="warning" %}
These values are retained here as originally reported and should not be interpreted as performance specifications for current 3D-PAWS sensors.
{% endhint %}

Relative humidity showed greater variability than the other evaluated measurements, including bias at very low and very high humidity and larger-than-expected errors across the middle of the measurement range.

***

#### Interpreting the Historical Results

The 2016–2017 evaluation demonstrated that the early 3D-PAWS system could produce useful meteorological observations when compared with calibrated reference instruments. It also identified areas for improvement, particularly relative humidity measurement.

These results helped inform the continued development of 3D-PAWS.

**The system has evolved substantially since this evaluation, including changes to sensors, electronics, 3D-printed components, software, and deployment practices.**

For this reason, the results on this page should be viewed as a **historical performance baseline rather than a characterization of the current 3D-PAWS system**.

***

#### Current Validation

3D-PAWS continues to be evaluated as the system develops.

A more recent independent comparison of 3D-PAWS observations with a reference weather station has been conducted through **TSMS**. Results are expected in a forthcoming **WMO report**.

Once the final report is available, its findings will be incorporated into this manual to provide a more current independent assessment of 3D-PAWS performance.

Until then, users should evaluate observations from individual deployments using the current siting, installation, metadata, maintenance, and data-quality guidance provided throughout this manual.


# Terms of Use

Licensing terms for 3D-PAWS software, hardware, print files, and documentation.

### Overview

3D-PAWS is committed to open science, open-source development, and transparent sharing.

Different components of the 3D-PAWS project are distributed under different open licenses. This page provides an overview of those licenses and how to properly attribute 3D-PAWS materials.

{% hint style="info" %}
This page summarizes the licensing approach used by 3D-PAWS. For complete legal terms and requirements, refer to the applicable license and the LICENSE files included with individual 3D-PAWS repositories.
{% endhint %}

***

#### Software

**Licenses: Apache License 2.0 and MIT License**

3D-PAWS software components are released under the [**Apache License 2.0**](https://3dpaws.comet.ucar.edu/3d-printed-automatic-weather-station-3d-paws/terms-of-use#:~:text=Licenses%3A-,Apache%20License%202.0,-and%20MIT%20License) and the [**MIT License**](https://opensource.org/license/mit).

You may use, modify, and distribute the software, including for commercial purposes, provided that you comply with the terms of the applicable license.

Refer to the **LICENSE** file in each software repository for the license that applies to that project and for complete legal terms and attribution requirements.

***

#### 3D-Print Files and Hardware

**License: CERN Open Hardware License Version 2 (CERN OHL v2)**

3D-printable files, hardware designs, and kit documentation are licensed under the [**CERN Open Hardware License Version 2**](https://gitlab.com/ohwr/project/cernohl/-/wikis/uploads/3eff4154d05e7a0459f3ddbf0674cae4/cern_ohl_p_v2.txt).

This license allows the designs to be used, modified, and distributed while maintaining open access to modifications and derivative hardware designs.

If you distribute modified versions, you must also share those changes in accordance with the applicable license terms.

Refer to the LICENSE file included with the hardware repository for complete requirements.

***

#### Documentation

**License: Creative Commons Attribution 4.0 International (CC BY 4.0)**

3D-PAWS website content, written guides, and documentation are licensed under the [**Creative Commons Attribution 4.0 International License (CC BY 4.0)**](https://creativecommons.org/licenses/by/4.0/).

You may copy, redistribute, adapt, and build upon the documentation for any purpose, including commercial use, as long as appropriate credit is provided.

***

#### How to Attribute 3D-PAWS

When reusing or adapting 3D-PAWS materials, include:

* the project name: **3D-PAWS**
* the applicable license
* a link to the original 3D-PAWS website or repository
* an indication of whether changes were made

**Example attribution for documentation:**

> Content adapted from 3D-PAWS (<https://3dpaws.comet.ucar.edu/>), licensed under CC BY 4.0.

{% hint style="info" %}
Software and hardware repositories may have specific attribution or notice requirements. Always check the LICENSE and related files in the repository you are using.
{% endhint %}

***

#### Questions and Contributions

Questions about licensing, reuse, or attribution can be directed to the 3D-PAWS team.

**Email:** <icdp_staff@comet.ucar.edu>

You can also submit questions, issues, or contributions through the appropriate 3D-PAWS GitHub repository.

By contributing to 3D-PAWS, you agree that your contributions will be licensed under the terms applicable to the corresponding project component.


# Building 3D-PAWS

Overview of station assembly, power options, framing, and the step-by-step build sections for 3D-PAWS.

<div data-full-width="false"><figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2F17ralIsV6BPtHUyIt7al%2FScreenshot%202026-04-01%20at%2012.06.55%E2%80%AFPM.png?alt=media&amp;token=1f15717b-9944-44bd-8645-04fb6b382c78" alt=""><figcaption></figcaption></figure></div>

## Building the 3D-PAWS

The image above shows the current design of the **3D-Printed Automatic Weather Station (3D-PAWS)**. A typical configuration includes the following sensors:

* 3-cup anemometer (wind speed)
* Wind vane (wind direction)
* Tipping bucket rain gauge (precipitation)
* Temperature and relative humidity sensor
* Atmospheric pressure sensor

Depending on the monitoring objectives, additional sensors can be added or existing sensors can be omitted.

***

## Station Structure

The 3D-PAWS system is designed to be **modular and adaptable**, allowing it to be installed on a variety of mounting structures.

The current reference design uses **PVC pipe framing**, which is inexpensive, lightweight, and widely available. However, stations can also be constructed using:

* aluminum framing
* metal pipe
* wood structures

The choice of structure typically depends on the deployment environment, available materials, and long-term durability requirements.

***

## Electronics and Power

The data logger is housed in a **waterproof enclosure** mounted on the station frame.

Power for the system can be supplied using:

* **Commercial power** (5V input), or
* **Solar power with battery storage**

When using solar power, the required **battery capacity and solar panel size** depend on the deployment location and expected solar availability.

***

## Assembly Instructions

The following sections provide step-by-step instructions for assembling the 3D-PAWS instruments and station components.

Each instrument page includes:

* required tools
* a parts list
* assembly instructions
* diagrams or reference images


# Getting Started

Overview of the preparation steps, resources, and core guidance needed before building and deploying a 3D-PAWS station.

### Overview

Before beginning assembly, review the [**3D-PAWS Build and Deployment Roadmap**](/building-3d-paws/getting-started/3d-paws-build-and-deployment-roadmap) to understand the overall process from component preparation through field deployment and long-term maintenance.

Then use the pages in this section to prepare for your build.

***

#### 3D Printing Components

Review guidance for printing and preparing the structural components used to build a 3D-PAWS station, including:

* recommended filament and printing practices
* filament storage and humidity control
* support removal and part finishing
* thread preparation and dry fitting

Proper preparation of printed parts improves assembly and long-term durability in the field.

→ See [**3D Printing Components**](/building-3d-paws/getting-started/3d-printing-components)

***

#### Materials and Tools

Review the parts, hardware, sensors, and tools required before beginning assembly.

This includes:

* station parts and hardware
* recommended assembly tools
* sensor-specific components
* parts for optional instruments

Confirm that the required materials are available before starting your build.

→ See [**Materials and Tools**](#materials-and-tools)

***

#### Cables and Connectors

Review the cabling and connector guidance before wiring sensors to the data logger.

This includes:

* connector selection
* I²C cable configuration
* strain relief and cable protection
* corrosion protection for outdoor deployments

Proper cable preparation and routing are important for reliable long-term operation.

→ See [**Cables and Connectors**](/building-3d-paws/getting-started/cables-and-connector-systems)

***

#### Ready to Build?

Once the printed components, materials, tools, and cables are prepared, continue to the instrument assembly pages to begin building the station components.


# 3D-PAWS Build and Deployment Roadmap

End-to-end roadmap for preparing, building, deploying, and maintaining a 3D-PAWS station.

### Overview

The 3D-PAWS Build and Deployment Roadmap shows the major stages involved in taking a station from initial preparation through field deployment and long-term operation.

Use the roadmap to understand the overall workflow and identify the manual sections and resources needed at each stage.

{% hint style="info" %}
The roadmap provides an overview of the process. Detailed instructions, checklists, and supporting resources are provided in the corresponding sections of this manual.
{% endhint %}

***

#### Build and Deployment Roadmap

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FWCpR4wbvtGNib6bgGpiY%2FScreenshot%202026-08-12%20at%2011.12.12%E2%80%AFAM.png?alt=media&amp;token=ce0b1033-9626-4f8e-9429-2d194ce7e558" alt=""><figcaption></figcaption></figure>

***

#### Using the Roadmap

Follow the roadmap from preparation through ongoing station operation. Depending on the station configuration and deployment, some steps may vary or may not apply.

Use the left-hand navigation menu to access detailed instructions for each stage.


# 3D-Printing Components

Guidance for downloading print files, choosing filament, and preparing 3D-printed parts for reliable station assembly.

### Overview

3D-PAWS stations use 3D-printed structural components designed for continuous outdoor use.

Use the **Instruction Slides for 3D-Printing Components** below for step-by-step guidance on:

* setting up the printer
* selecting and loading filament
* downloading and identifying print files
* checking print settings
* printing components
* cleaning and preparing parts
* storing filament
* maintaining the 3D printer

{% hint style="info" %}
The instruction slides use **Bambu Studio** to demonstrate the printing process. Other slicer software may differ, but the overall workflow is similar. Refer to your printer and slicer documentation for platform-specific instructions.
{% endhint %}

***

#### Downloading the 3D-PAWS Print Files

Official 3D-PAWS print files are available in the public GitHub repository:

[**3D-PAWS Print Files**](https://github.com/3d-paws/3D-PAWS-Print-Files)

Download the latest version before beginning a new build. Design updates are periodically released, so check the repository to ensure you are using the most current files.

***

#### Understanding the Print Files

The print files are organized by instrument and station component, but file names may not always be immediately intuitive.

To identify the correct parts:

* refer to the **parts list at the beginning of the relevant manual section**
* match file names to the listed components
* use diagrams in the manual to confirm part placement
* preview the `.stl` files in each folder to see what the parts look like before printing; previews show the parts without supports

Using the manual alongside the print repository makes it easier to identify the correct components.

***

#### Instruction Slides for 3D-Printing Components

{% embed url="<https://docs.google.com/presentation/d/1LiI6rCuBNRMM3SOFoJJzer6RM_LR2lNtWXXPFkfdFZ8/edit?usp=sharing>" %}

The slides provide the detailed printing and part-preparation procedures for 3D-PAWS components.

***

#### Before Printing

A few key requirements apply to most 3D-PAWS builds:

* **Filament:** ASA is recommended for most outdoor components
* **Radiation shield:** use white, opaque ASA
* **Filament quantity:** approximately 2 kg per typical station
* **Printer build volume:** minimum approximately **200 mm × 200 mm × 200 mm**
* **Project files:** use the provided `.3mf` files whenever possible because they contain tested orientation and support settings

Refer to the instruction slides for detailed print settings and procedures.

***

#### Tutorial Video for Preparing Printed Parts

{% embed url="<https://www.youtube.com/watch?v=y_kMS7YrmLM>" %}

#### Safety When Preparing Printed Parts

{% hint style="warning" %}
Wear appropriate personal protective equipment when removing supports and preparing printed parts.

* Wear **safety glasses or eye protection**. Small pieces of support material may break free during removal.
* Use **protective gloves** when appropriate.
* Cutters, knives, picks, and pliers may have sharp edges. Use them carefully and keep hands clear of cutting paths.
* Remove supports slowly and in a controlled manner to reduce the risk of flying debris or damaged parts.
  {% endhint %}

Refer to the instruction slides for procedures for removing supports, cleaning mating surfaces, preparing threaded components, and dry-fitting parts before assembly.

### Related Resource

* [3D-Printer Maintenance](/other-3d-paws-resources/3d-printer-maintenance)


# Materials and Tools

Spreadsheet of required tools, non-printed parts, and sensor-specific materials for 3D-PAWS builds.

Before beginning a 3D-PAWS build, review the required materials and tools needed for assembling the station.

Most structural components of the station are **3D printed**, but additional hardware, sensors, and tools are required for assembly and deployment.

The **Materials and Tools spreadsheet** provides a complete list of the non-printed components needed to build and operate a 3D-PAWS station.

The spreadsheet includes:

* A complete **3D-PAWS parts list**
* **Recommended tools** for assembling the station
* **Sensor-specific parts lists** for the core instruments
* Parts required for optional instruments such as:
  * Stream or storm surge gauges
  * Snow gauges

Review this spreadsheet before beginning your build to ensure that all required components are available.

→ [**Open the Materials and Tools Spreadsheet**](https://docs.google.com/spreadsheets/d/10M0B0uvYnA0v-_q23aUk9Q1RNNS-oWH9inRZntQyyuM/edit?usp=sharing)


# Cables and Connector Systems

An introduction to the cables, connectors, and signal types used to connect 3D-PAWS sensors, data loggers, and power systems.

### Overview

3D-PAWS uses several cable and connector systems to provide flexible and reliable connections between sensors, data loggers, and other station components.

The **Cables and Connectors instruction slides** below explain:

* Grove and Qwiic connectors
* Dupont wiring
* I²C communication
* digital pulse signals
* analog voltage signals
* male and female connectors
* multi-port hubs
* cable management and wiring best practices
* common wiring issues

{% hint style="info" %}
The instruction slides explain how 3D-PAWS cables, connectors, and signal types work.

For the wiring configuration of a specific data logger, use the wiring diagrams provided on that data logger's page in the **Setting Up the Data Logger** section.
{% endhint %}

***

#### Cables and Connectors Instruction Slides

{% embed url="<https://docs.google.com/presentation/d/12kHUk7uuHCU6cKMtkYReJbJd0hgLPdv-N7W6DK6QLdY/view?slide=id.g3edce1eb01e_0_0#slide=id.g3edce1eb01e_0_0>" %}

Use these slides as the primary reference for understanding the cable, connector, and signal systems used by 3D-PAWS.

***

#### Connector Systems Used by 3D-PAWS

3D-PAWS primarily uses:

* **Grove** – the preferred modular connector system for many current 3D-PAWS connections
* **Qwiic** – a modular connector system used in earlier 3D-PAWS configurations
* **Dupont** – individual male and female connections used where direct or flexible wiring is required
* **Multi-port hubs** – provide additional connection points where supported

Although Grove and Qwiic connectors may look different and use different wire colors, both can carry the same types of electrical signals when wired appropriately.

Always verify connector orientation and pin assignments rather than relying only on wire color.

***

#### Connector Type vs. Signal Type

The physical connector does not determine how a sensor communicates.

A Grove-style or similar connector may carry different types of signals depending on the instrument and data logger configuration.

3D-PAWS commonly uses three signal types:

* **I²C** – digital communication over shared SDA and SCL lines
* **Digital pulse** – HIGH/LOW switching signals that are detected or counted by the data logger
* **Analog voltage** – a changing voltage measured by the data logger's analog-to-digital converter

{% hint style="info" %}
A sensor connected to a pin labeled as an analog input is not necessarily an analog sensor. Many analog-capable data logger pins can also operate as digital GPIO inputs.
{% endhint %}

***

#### Examples

| Signal Type        | How It Works                                                                                | 3D-PAWS Examples                                                              |
| ------------------ | ------------------------------------------------------------------------------------------- | ----------------------------------------------------------------------------- |
| **I²C**            | Devices communicate digitally over shared SDA and SCL lines using unique addresses          | Wind vane; temperature, humidity, and pressure sensors; other I²C instruments |
| **Digital Pulse**  | The sensor switches between digital states and the data logger detects or counts each pulse | Rain gauge; anemometer                                                        |
| **Analog Voltage** | Output voltage changes in proportion to the measured value and is read by an ADC            | Ultrasonic distance sensor when using its analog-voltage output               |

***

#### Wiring Diagrams

Detailed wiring diagrams and pin assignments are provided in the documentation for each data logger.

Use the appropriate data logger page when assembling or troubleshooting station wiring:

* [**Particle Data Logger**](/building-3d-paws/setting-up-the-data-logger/particle-iot)
* [**Raspberry Pi Data Logger**](/building-3d-paws/setting-up-the-data-logger/raspberry-pi)
* [**Adafruit Feather**](/building-3d-paws/setting-up-the-data-logger/adafruit-feather-m0)
* [**Arduino MKR**](/building-3d-paws/setting-up-the-data-logger/arduino-mkr)

{% hint style="warning" %}
Always verify the wiring diagram and sensor pinout for your specific data logger before applying power. Do not rely on wire color alone.
{% endhint %}


# 3D-PAWS User Forum

Community forum for asking questions, sharing deployment experience, and collaborating with other 3D-PAWS builders.

The [**3D-PAWS User Forum**](https://3dpaws.discourse.group/) is a dedicated space for the 3D-Printed Automatic Weather Station (3D-PAWS) initiative, an innovative UCAR project that enables communities worldwide to build reliable weather stations using 3D printing technology. Here, weather enthusiasts, scientists, educators, and technologists can connect, share knowledge, resolve questions, and collaborate to expand global weather monitoring capabilities.

In the forum, you can:

* Introduce yourself and meet other community members.
* Participate in technical discussions and share your experiences with 3D-PAWS.
* Ask questions, provide solutions, and offer feedback.
* Access additional resources, guides, and manuals related to 3D-PAWS.

The forum encourages open collaboration and the exchange of ideas to make weather data collection more accessible, affordable, and community-driven. From Kenya to Barbados, 3D-PAWS stations are helping to close critical gaps in global weather observation.

Join and become part of an international network advancing open science and innovation in environmental monitoring!

{% embed url="<https://3dpaws.discourse.group/>" %}


# Glossary of Terms


# Building the Core Instruments

Assembly overview for the four core instruments used in a typical 3D-PAWS weather station.

### Overview

A typical 3D-PAWS weather station includes four core instruments:

* [**Rain Gauge**](/building-3d-paws/building-the-core-instruments/tipping-bucket-rain-gauge) – measures precipitation
* [**Anemometer**](/building-3d-paws/building-the-core-instruments/anemometer) – measures wind speed
* [**Wind Vane**](/building-3d-paws/building-the-core-instruments/wind-vane) – measures wind direction
* [**Radiation Shield**](/building-3d-paws/building-the-core-instruments/radiation-shield) – houses sensors used to measure air temperature, relative humidity, and atmospheric pressure

These instruments use 3D-printed components, sensors, and standardized wiring connections that are assembled before being connected to the data logger and installed on the station.

Detailed assembly procedures, parts lists, sensor information, and testing guidance are provided on the individual instrument pages.

{% hint style="info" %}
The core instruments can be assembled in any order. However, the **rain gauge typically requires additional time for calibration**, so it may be helpful to assemble it early in the build process.
{% endhint %}

***

#### After Assembly

Once the core instruments are assembled, connect them to the  Raspberry Pi and verify that the sensors are operating correctly before field deployment. See [**Testing the Sensors**](/building-3d-paws/building-the-core-instruments/testing-the-sensors).

***

#### Additional Instruments

3D-PAWS can also be configured with additional instruments for other environmental measurements, including water level, snow depth, soil conditions, air quality, and heat stress.

See [**Adding Additional Instruments**](/building-3d-paws/adding-additional-instruments) for available configurations.


# Tipping Bucket Rain Gauge

Build and calibration guide for the tipping bucket rain gauge, including sensor setup, funnel rim sizing, and screening.

### How the Sensor Works

The tipping bucket rain gauge measures precipitation by collecting rainwater in a small bucket that tips when a certain volume is reached. With each tip, a magnet triggers an [**SS451A Hall effect sensor**](https://drive.google.com/file/d/11g7WHNxx8yAw96QL7NoBcTuqBucDBsyk/view?usp=sharing) to record rainfall increments digitally, ensuring accurate and reliable data collection.

The tipping bucket rain gauge is calibrated to ensure each tip corresponds to a standardized rainfall depth (e.g., 0.2 mm per tip) using the volume of a cylinder to determine the required rim radius of the collector funnel.

### Instruction Slides for Assembling the Rain Gauge

{% embed url="<https://docs.google.com/presentation/d/1DO-Jg0TDZVEAp2Xe-rkrB-jUjcxNXFZo/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

### Tutorial Videos for Assembling the Rain Gauge

This video playlist demonstrates the entire assembly of the instrument. You can toggle between assembly videos using the "fast forward" and "rewind" buttons.

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf259GXU1qn3kQDZLy38TNb8&si=oRcC0q3brffaI-r4>" %}

## Calibrating the Rain Gauge

#### The rain gauge is calibrated through a multi-step process to ensure accuracy.

1. First, the tipping bucket mechanism is "bedded in" by cycling it approximately 1,000 times to reduce mechanical resistance.
2. Next, water is pumped into the funnel to generate around 500 tips, and the total volume of water that passes through is collected and weighed. By dividing the total water mass (grams) by the number of tips, the system determines the **grams of water per tip**.
3. Using the density of pure water (1 gram = 1,000 mm³), this mass is converted to volume (mm³).
4. The target rainfall depth per tip—**0.2 mm** is then applied to the **volume of a cylinder** formula (**V=πr**<sup>**2**</sup>**h**).
5. Rearranging the equation to solve for radius , the funnel’s rim size is calculated to ensure each tip corresponds precisely to the desired rainfall depth.

$$
r = \sqrt{\frac{V}{\pi h}}
$$

This process bridges empirical testing (weighing water) with geometric principles (cylinder math), ensuring the gauge meets standardized meteorological requirements.

**Please use the** [**Rain Gauge Calibration Spreadsheet**](https://docs.google.com/spreadsheets/d/1zfsArjV74BdeZ6WYWBsjU9aRDrJ3M1A3qX7iNRu8XcM/view?usp=sharing) **as an aid in the calibration process**

### Using a Raspberry Pi to Calibrate the Rain Gauge

{% content-ref url="/pages/HiggTiSMUVo7rbZde5hE" %}
[Testing the Sensors](/building-3d-paws/building-the-core-instruments/testing-the-sensors)
{% endcontent-ref %}

### **Instruction Slides for Calibrating the Rain Gauge**

**Note:** *Due to the constant adjustment of the Pumped Drip Controller, we have moved to a new method of controlling the flow rate for calibration.*

{% embed url="<https://docs.google.com/presentation/d/1XSYiw7RjXnMcyZn_ZsYk4cZq0WHcFuqq/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=drive_link>" %}

{% embed url="<https://docs.google.com/presentation/d/1PEHFb6Z6ehP9tLQ6WGRP_NY_aasIgI7k/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=drive_link>" %}

### Tutorial Videos for Calibrating the Rain Gauge

This video playlist demonstrates the entire assembly of the instrument. You can toggle between assembly videos using the "fast forward" and "rewind" buttons.

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf3reOQzjbbnhwwKe_w04bFS&si=uqeMSu7EmrZ9qOQ8>" %}

#### Adding the Screens

The rain gauge screen serves as a protective barrier, preventing debris from entering the funnel and interfering with the tipping bucket mechanism. By filtering out leaves, twigs, and other particles, it ensures accurate and reliable rainfall measurements. This screen is crucial for maintaining the gauge's precision and longevity, especially in outdoor environments where debris accumulation is common.

### Instruction Slides for Adding the Screens

{% embed url="<https://docs.google.com/presentation/d/1QJsi6iLc8YyqHZT1T_WK9rKSxn1998Jn/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}


# Anemometer

Assembly guide for the anemometer, including Hall effect sensor setup and wind speed measurement basics.

### How the Sensor Works

The three-cup anemometer measures **wind speed** using a **Hall effect sensor (SS451A)** that detects rotations. Two magnets on the anemometer generate 2 interrupts per revolution, enabling precise tracking of rotational speed. Wind speed is sampled **every second** by recording interrupt counts and millisecond durations. These 1-second samples are converted into instantaneous wind speeds using the anemometer’s calibration factor. Observations are logged every minute, with:

* **Wind Speed**: Average of 60 consecutive 1-second samples.
* **Wind Gust**: Highest 3-second average (three consecutive samples).

Wind speed is calculated using:<br>

$$
\text{Speed (m/s)} = \left( \frac{\frac{\text{interrupts}}{2} \cdot 2\pi \cdot \text{radius}}{\text{time (s)}} \right) \cdot \text{calibration factor}
$$

* **Radius**: 0.079 meters (distance from center to cup)
* **Calibration factor**: 2.64 (empirically determined from wind tunnel testing)

### Instruction Slides for Assembling the Anemometer

{% hint style="info" %}
We recently updated the threaded shaft assemblies for the anemometer and wind vane. The new design adds a 12 mm nylon M6 set screw to improve the durability of the anemometer hub and wind vane rotor. Use the latest 3D-printed parts from the [GitHub print files page](https://github.com/3d-paws/3D-PAWS-Print-Files).
{% endhint %}

{% embed url="<https://docs.google.com/presentation/d/1YngCZ7LndUnrU6fsVEQOx-qzNQy3Zqwt/view?slide=id.p1#slide=id.p1>" %}

### Tutorial Videos for Assembling the Anemometer

This video playlist demonstrates the entire assembly of the Anemometer. **It demonstrates the glue in version of the bearing housing and hub using Qwiic cables. Please follow the manual instructions if using the twist version of the bearing housing or M5 stack Grove cables.**

This video playlist demonstrates the entire assembly of the instrument. You can toggle between assembly videos using the "fast forward" and "rewind" buttons.

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf0pVc3sgLi5L2UCpbDumTmw&si=yCZf57mjFfVSm7Mz>" %}


# Wind Vane

Assembly guide for the wind vane, including magnetic encoder setup and alignment.

### How the Sensor Works

The wind vane uses the [**AS5600**](https://drive.google.com/file/d/1f8m0zBGUlcEmwGa42xqODvVKy_ajvcer/view?usp=sharing) magnetic encoder to measure the angular position of the vane as it aligns with wind flow. Direction is sampled every second and combined with wind speed data to form vectors. These vectors are averaged over 60 seconds to calculate the mean wind direction, while the peak gust direction is determined by averaging the three vectors corresponding to the highest 3-second wind speed period.

### Instruction Slides for Assembling the Wind Vane

{% hint style="info" %}
We recently updated the threaded shaft assemblies for the anemometer and wind vane. The new design adds a 12 mm nylon M6 set screw to improve the durability of the anemometer hub and wind vane rotor. Use the latest 3D-printed parts from the [GitHub print files page](https://github.com/3d-paws/3D-PAWS-Print-Files).
{% endhint %}

{% embed url="<https://docs.google.com/presentation/d/15pcZ-m701CntkEu2e7mfiA9Nk9n1EzvD/view?slide=id.p1#slide=id.p1>" %}

### Aligning the Wind Vane to North (0°)

Follow the directions at the bottom of "Testing the Sensors" to align the pointer to North (0°)

{% content-ref url="/pages/HiggTiSMUVo7rbZde5hE" %}
[Testing the Sensors](/building-3d-paws/building-the-core-instruments/testing-the-sensors)
{% endcontent-ref %}

### Tutorial Videos for Assembling the Wind Vane

This video playlist demonstrates the entire assembly of the instrument. You can toggle between assembly videos using the "fast forward" and "rewind" buttons.

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf02LAZGMwgVSpYQ5ltpMpbt&si=GauiSj5z5saHrMz6>" %}


# Radiation Shield

Assembly and wiring guide for the radiation shield and its temperature, humidity, and pressure sensors.

### How the Sensors Work

The radiation shield houses integrated environmental sensors to ensure accurate readings:

* **Temperature:** Temperature measurements are provided by the **SHT31D**, **MCP9808**, and **BMP390** sensors. The SHT31D and MCP9808 use precision semiconductor temperature-sensing elements whose electrical characteristics change predictably with temperature, enabling accurate, linear temperature measurements without a separate thermistor component. The BMP390 also measures temperature internally, providing a supplementary temperature observation as part of its pressure compensation system. Using three temperature sensors enables measurement verification, quality control, and improved confidence in reported environmental conditions.
* **Relative Humidity:** Relative humidity is measured by the **SHT31D** using a moisture-sensitive polymer sensing element. As the amount of water vapor in the air changes, the capacitance of the sensing element changes proportionally, allowing the sensor to determine relative humidity.
* **Atmospheric Pressure:** Atmospheric pressure is measured by the **BMP390** barometric pressure sensor. The sensor uses a micro-electromechanical (MEMS) silicon diaphragm that flexes in response to changes in atmospheric pressure. These microscopic deflections are detected by piezoresistive elements embedded within the diaphragm and converted into highly accurate digital pressure measurements.

**Wiring**:\
All three sensors connect via **I2C** (shared SDA/SCL lines) to minimize wiring complexity. The radiation shield’s passive ventilation design protects sensors from direct sunlight, precipitation, and debris while maintaining airflow for precision.

### Instruction Slides for Wiring the Sensors

{% embed url="<https://docs.google.com/presentation/d/1diS6moU7ZcuMMJtIDO2LEwxRn5aVLM7N/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

## Assembling the Radiation Shield

The radiation shield is a passively ventilated enclosure that protects temperature, humidity, and pressure sensors from environmental interference while maintaining airflow for accurate measurements. Its multi-plate design minimizes exposure to direct sunlight, precipitation, and debris, while allowing ambient air circulation. The shield reduces radiative heating and thermal inertia, ensuring sensors measure true ambient air conditions rather than artificial microclimates.

### Instruction Slides for Assembling the Radiation Shield

{% embed url="<https://docs.google.com/presentation/d/1QULsoqzH89nLaFRf2utPK3nYZIs7HVXe/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

### Tutorial Video for Assembling the Radiation Shield

This video demonstrates the entire assembly of the instrument. There is only one video in this particular playlist.

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf1Y88Ddw8Gxk7ubF22Zb2Bt&si=ODQ-XtooZQkHrUPF>" %}


# Testing the Sensors

Guide to verifying 3D-PAWS sensors on a Raspberry Pi before field installation and deployment.

Before installing instruments on the weather station, it’s crucial to test all sensors to ensure they’re working correctly. This can be done using a **Raspberry Pi** equipped with a **Grove Base Hat**, which provides easy connections for various sensors. The [**3D-PAWS software**](https://github.com/3d-paws/3D-PAWS-Raspberry-Pi), available on GitHub, simplifies the testing process by handling sensor data acquisition and communication. By following this setup, you can validate sensor functionality and accuracy in a controlled environment before deploying them in the field.

You can test the following sensors on the Raspberry Pi at this time:

* Anemometer
* Wind Vane
* Tipping Bucket Rain Gauge
* Temperature, Pressure, Relative Humidity sensors
* Light Sensor

### Instruction Slides for Testing the Instruments

{% embed url="<https://docs.google.com/presentation/d/1hD3eILlqyNSR8FFSMMMtzDM08AuKyfK_/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

### Tutorial Video for Aligning the Wind Vane to 0° (N)

This video demonstrates testing the Wind Vane.&#x20;

{% embed url="<https://youtu.be/b_W97jlTpdk?si=vrGWDWjK9VjB1J1r>" %}


# Adding Additional Instruments

Optional sensors and instruments for expanding 3D-PAWS beyond the core meteorological measurements.

### Overview

In addition to the core weather instruments, 3D-PAWS stations can be configured with additional sensors to support specific environmental monitoring needs.

Additional instruments can be included during the initial station build or integrated later as monitoring requirements change.

***

#### Available Additional Instruments

3D-PAWS supports additional instruments for measuring:

* **Water Level** – stream height and storm surge
* **Snow Depth** – snow accumulation
* **Soil Moisture and Temperature** – soil and agricultural conditions
* **Air Quality** – particulate matter
* **Black Globe Temperature** – radiant heat exposure
* **Light** – visible, infrared, and ultraviolet radiation

Detailed information about each instrument, including assembly, sensors, wiring, and installation considerations, is provided on the individual pages in this section.

***

#### Planning Additional Instruments

Before adding an instrument, consider:

* the environmental variable you need to measure
* available mounting locations
* sensor siting and exposure requirements
* data logger compatibility and available inputs
* power requirements
* communications and data requirements

{% hint style="info" %}
Not every additional instrument is compatible with every data logger or station configuration. Review the documentation for the selected instrument and data logger before beginning assembly.
{% endhint %}

***

#### After Adding an Instrument

After assembly and connection, verify that the instrument is functioning correctly and that observations are being received by the data logger before deployment.


# Stream/Storm Surge Gauge

Build and deployment guidance for using an ultrasonic distance sensor to monitor stream level and storm surge.

### Overview

The 3D-PAWS Stream/Storm Surge Gauge uses a **MaxBotix MB7363 or MB7364 HRXL-MaxSonar-WRLS ultrasonic distance sensor** mounted above the water surface.

The sensor measures the distance between itself and the water surface. Changes in that distance can be used to monitor changes in water level.

Typical applications include:

* stream stage monitoring
* flood monitoring
* storm surge monitoring

The **MB7363** provides a measurement range of up to approximately **10 m**, while the **MB7364** provides a range of up to approximately **5 m**.

{% hint style="info" %}
Use the **extended horn** configuration for the Storm Surge Gauge.
{% endhint %}

***

#### How the Sensor Works

The ultrasonic sensor emits an acoustic pulse toward the water surface and measures the returning echo.

As the water level rises, the distance between the sensor and the water surface decreases. As the water level falls, the measured distance increases.

Because the measurement depends on an unobstructed acoustic path, the location and mounting geometry of the sensor are important.

***

#### Instruction Slides for Assembling the Stream Gauge

{% embed url="<https://docs.google.com/presentation/d/1MNQdw-ZgiPDAaeQpxELebeudVM-F4yri/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

Use these slides for step-by-step assembly of the ultrasonic sensor and associated components.

***

#### Stream Gauge Frame

{% embed url="<https://docs.google.com/presentation/d/1nQdoJoT5c6aCyYo4U0bEMxQ9Z9vi58mC/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

The mounting frame can be adapted to different installation environments. The sensor should be positioned so that its acoustic beam has a clear path to the water surface.

***

#### Ultrasonic Sensor Boom Geometry

The ultrasonic sensor emits a narrow acoustic beam. Nearby structures such as the mast, bridge, seawall, or other mounting surfaces can produce unwanted reflections if they enter the beam path.

The boom should extend far enough from nearby structures to keep the sensor's acoustic beam clear between the sensor and the water surface.

For planning purposes, this guidance assumes a conservative **20° full beam angle**.

#### Simple Rule for Boom Length

If the mast is installed at the edge of the measurement area:

**Every 1 m of sensor height requires approximately 0.18 m of horizontal boom extension.**

$$
L \approx 0.176h
$$

where:

* **L** = minimum boom length (m)
* **h** = sensor height above the water surface (m)

#### Recommended Boom Lengths

| Sensor Height Above Water | Minimum Boom Length | Recommended with Margin |
| ------------------------: | ------------------: | ----------------------: |
|                       1 m |              0.18 m |                  0.25 m |
|                       2 m |              0.35 m |                  0.45 m |
|                       3 m |              0.53 m |                  0.60 m |
|                       4 m |              0.71 m |                  0.80 m |
|                       5 m |              0.88 m |                  0.95 m |
|                       6 m |              1.06 m |                  1.15 m |
|                       7 m |              1.23 m |                  1.35 m |
|                       8 m |              1.41 m |                  1.55 m |
|                       9 m |              1.59 m |                  1.75 m |
|                      10 m |              1.76 m |                  1.95 m |

The recommended values include approximately **50–100 mm of additional clearance** to account for mast movement, uneven surfaces, and variations in beam spread.

#### If the Mast Is Set Back from the Edge

If the mast is installed some distance from the edge, add that distance to the calculated boom length:

$$
L \approx (0.176h) + d\_{\text{edge}}
$$

where:

* **L** = minimum boom length (m)
* **h** = sensor height above the water surface (m)
* **dₑdge** = horizontal distance from the mast to the edge (m)

{% hint style="warning" %}
The sensor must have a clear acoustic path to the water surface. Before installation, check that the mast, boom, bridge, seawall, vegetation, or other nearby objects do not enter the sensor's measurement beam.
{% endhint %}

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FcX3AjvvTFHcjrKGjb7Ri%2FScreenshot%202025-10-24%20at%204.10.43%E2%80%AFPM.png?alt=media&amp;token=86cb97c5-ad4f-49d0-a0ee-980c25debbbd" alt=""><figcaption></figcaption></figure>


# Snow Gauge

Build guide for a non-contact snow depth sensor using ultrasonic and temperature compensation.

### How the Sensor Works

The snow gauge in the 3D-PAWS system measures snow depth using a combination of ultrasonic and temperature sensing technologies. Mounted above the ground, the MaxBotix HRXL-MaxSonar-WRLS ultrasonic sensor emits high-frequency sound pulses toward the snow surface. These pulses reflect off the snow, and the sensor measures the time it takes for the echo to return. By calculating this time and accounting for the speed of sound in air, the system determines the distance from the sensor to the snow surface. As snow accumulates, this distance decreases, allowing for continuous tracking of snow depth.

To ensure accurate measurements in all weather conditions, the system uses an external MB79XX HR-MaxTemp temperature sensor. This sensor monitors the air temperature near the ultrasonic sensor, allowing the system to automatically adjust for changes in the speed of sound caused by temperature fluctuations. This dual-sensor approach provides reliable, real-time snow depth data, even during periods of rapid temperature change.

### Instruction Slides for Assembling the Snow Gauge

{% embed url="<https://docs.google.com/presentation/d/1YO5O1ntEGBZHQfLsdorJPArX3SR6ezxX/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}


# Air Quality

Build guide for a particulate matter sensor with PM2.5 monitoring and higher-power station requirements.

The **PMSA003I** is a high-precision laser-based particulate matter (PM) sensor designed for real-time air quality monitoring in the 3D-PAWS system. This sensor continuously measures and reports the concentration and number of airborne particles of various sizes, providing detailed insight into local air pollution.

### How the Sensor Works

* **Laser Scattering Principle:** The PMSA003I uses a laser and a fan to draw air into its detection chamber. As particles pass through the laser beam, scattered light is detected and analyzed to determine particle size and count.
* **Particle Output:** The sensor outputs both the **number and mass concentration** of particles in several size bins (e.g., PM1.0, PM2.5, PM10); however, estimates of PM1.0 and PM10 are considered to be less reliable. We only recommend using the sensor for PM2.5 measurements.
  * **Number concentration** is reported as particles per 0.1 L of air.
  * **Mass concentration** is reported in micrograms per cubic meter (μg/m³).
* **Adaptive Sampling Modes:**
  * **Stable Mode:** When air quality is steady, the sensor samples at a real interval of 2.3 seconds.
  * **Fast Mode:** If particle concentrations change rapidly, the sensor automatically switches to fast mode, sampling every 200–800 ms. The higher the concentration, the faster the sampling.
* **3D-PAWS Integration:** The 3D-PAWS system samples the PMSA003I every second, recording the average 1-minute value observed during each measurement interval for robust air quality tracking.

### **Power Considerations & Recommendation**

> **Note:**\
> The PMSA003I is a **power-hungry sensor** because it runs a fan continuously to ensure accurate, real-time sampling. This significantly increases the station’s energy requirements.
>
> **For reliable operation, we strongly recommend using a Voltaic V75 battery and a 10 W, 6 V solar panel** for air quality stations equipped with this sensor.

### Instruction Slides for Assembling the Air Quality Sensor

{% embed url="<https://docs.google.com/presentation/d/1u3FngsENW0vul29Sv0nUXfPqT-J2vinB/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

#### Tutorial Video for Assembling the Air Quality Sensor

{% embed url="<https://youtu.be/sMaGJBv4Oxg?si=ZPNAruenqPnApDtO>" %}


# Black Globe

Build guide for a globe temperature sensor used to estimate radiant heat exposure and WBGT.

### How the Sensor Works

The Black Globe temperature sensor in the 3D-PAWS system uses the high-precision **MCP9808** digital temperature sensor to measure **globe temperature**—a critical factor in calculating Wet Bulb Globe Temperature (WBGT) for heat stress assessment. Housed inside a **matte black sphere**, this sensor captures the combined effects of ambient air temperature, solar radiation, and wind. The resulting data enables accurate WBGT calculations, which are essential for evaluating heat stress risk in outdoor environments. This information supports public health and safety initiatives by providing reliable, real-time monitoring for robust environmental assessment.

The Black Globe can be installed in lieu of the light sensor.

### Instruction Slides for Assembling the Black Globe

{% embed url="<https://docs.google.com/presentation/d/10f7Kl7-akeiOYw5JYsVV7JC69pQ60rG_/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

### Tutorial Video for Assembling the Black Globe

{% embed url="<https://www.youtube.com/watch?v=24oZ84Lmtvo>" %}


# Soil Moisture and Temperature

Guide to adding soil moisture and temperature sensors for single-depth or multi-depth subsurface monitoring.

### How the Sensors Work

The 3D-PAWS system supports two types of soil moisture sensors for monitoring subsurface conditions: the **Tinovi PM-WCS-3-I2C** and the **Tinovi SOIL-MULTI-5-I2C**. Both use non-contact capacitive sensing technology to measure the **volumetric water content (VWC)** and **temperature** of the soil. This approach minimizes corrosion and provides stable, long-term performance compared to traditional resistive sensors.

The **PM-WCS-3-I2C** measures soil moisture and temperature at a single depth and communicates via an I2C interface. Up to eight sensors can be connected using a Grove I2C Multiplexer (TCA9548A), allowing simultaneous monitoring at multiple depths or locations. The **SOIL-MULTI-5-I2C**, by contrast, measures VWC at five depths (10 cm, 20 cm, 30 cm, 40 cm, and 50 cm) and temperature at two depths (10 cm and 50 cm) along a single probe. Each level provides an averaged reading representative of conditions at that depth. Together, these sensors enable the 3D-PAWS system to produce detailed profiles of soil moisture and temperature, improving understanding of infiltration, root-zone processes, and overall soil water dynamics.

#### **Applications**

The soil moisture sensors are ideal for hydrological, agricultural, and environmental monitoring applications. They provide key data for studying soil-water balance, infiltration rates, root-zone moisture dynamics, and soil temperature gradients. When deployed as part of the 3D-PAWS network, these sensors support research on land–atmosphere interactions and improve understanding of how soil moisture influences weather, climate, and ecosystem processes.

### Instruction Slides for Adding the Tinovi PM-WCS-3-I2C

{% embed url="<https://docs.google.com/presentation/d/1gtIi9yG1OnERd5IsEoB5_NCDtpoBEdC1/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

### PM-WCS-3-I2C Installation Tool

{% embed url="<https://docs.google.com/presentation/d/1yaE_M_TYDpAXBLXzfsWneeV_LayQAZ7u/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

### Instruction Slides for Adding the Tinovi SOIL-MULTI-5-I2C

{% embed url="<https://docs.google.com/presentation/d/14ZWVra-Wjku8X4AlnEKnqbIBVQarVet6/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}


# Light Sensor

**Notice: The SI1145 light sensor is no longer stocked or available from Adafruit. We are working on an alternative sensor replacement at this time. You can use the** [**DFRobot Ambient Light Sensor**](https://www.dfrobot.com/product-2183.html) **with some slight modifications on the Particle Boron/Argon but we are still testing this sensor at this time.**&#x20;

The light sensor measures levels of visible light, infrared (IR), and ultraviolet (UV) radiation. It operates by detecting electromagnetic radiation through photodiodes sensitive to specific wavelengths of light. The Adafruit SI1145, based on the SiLabs sensor, is used for this purpose.

### Instruction Slides

{% embed url="<https://docs.google.com/presentation/d/1zQi5jS6oqQPbblSnSxkM0JDoJSToHvNy/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

### Tutorial Videos

This video playlist demonstrates the entire assembly of the instrument. You can toggle between videos using the list icon at the top right or by using the "fast forward" button at the bottom left.

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf0ebGJsHG2cwSM8zuX-Mu_I&si=u0fGZKc75kSKxWu2>" %}


# Setting Up the Data Logger

Compare the data logger platforms supported by 3D-PAWS and select the appropriate option for your deployment.

### Overview

3D-PAWS stations can operate using several data logger platforms. The appropriate platform depends on the station's communications requirements, available power, processing needs, and ability to support remote or on-site maintenance.

Currently supported platforms include **Particle (Boron / Argon), Raspberry Pi, Adafruit Feather, and Arduino MKR**.

The Particle platform is the most commonly used data logger for 3D-PAWS stations and is recommended for most remote operational deployments because of its integrated connectivity, cloud-based device management, and over-the-air firmware updates.

***

#### Data Logger Comparison

<table><thead><tr><th>Platform</th><th width="135.7628173828125">Connectivity</th><th>Power Use</th><th width="133.83099365234375">Firmware / Maintenance</th><th>Strengths</th><th>Typical Use</th></tr></thead><tbody><tr><td><strong>Particle (Boron / Argon)</strong></td><td>Cellular (Boron) or WiFi (Argon)</td><td>Low to moderate</td><td>Remote cloud management and OTA firmware updates</td><td>Remote management, reliable connectivity, easier maintenance</td><td>Operational remote weather networks</td></tr><tr><td><strong>Raspberry Pi</strong></td><td>WiFi; optional cellular modem</td><td>High</td><td>Linux-based system; typically requires more system administration</td><td>Advanced processing, local storage, highly customizable software</td><td>Research stations and custom data processing</td></tr><tr><td><strong>Adafruit Feather</strong></td><td>WiFi or LoRa, depending on configuration</td><td>Very low</td><td>Firmware updates typically require local access</td><td>Low power, flexible microcontroller platform, LoRa support</td><td>Ultra-low-power or distributed sensor networks</td></tr><tr><td><strong>Arduino MKR</strong></td><td>Cellular, depending on board</td><td>Low</td><td>Firmware updates typically require local access</td><td>Compact, low-power cellular microcontroller platform</td><td>Low-power cellular stations</td></tr></tbody></table>

{% hint style="info" %}
For most solar-powered remote 3D-PAWS stations, **Particle is the preferred platform** because it provides a strong balance of connectivity, power efficiency, and remote maintainability.
{% endhint %}

***

#### Platform-Specific Setup

Each data logger has its own hardware configuration, wiring, firmware, and communications setup.

Use the corresponding page in this section for detailed instructions:

* [**Particle Data Logger**](/building-3d-paws/setting-up-the-data-logger/particle-iot)
* [**Raspberry Pi Data Logger**](/building-3d-paws/setting-up-the-data-logger/raspberry-pi)
* [**Adafruit Feather Data Logger**](/building-3d-paws/setting-up-the-data-logger/adafruit-feather-m0)
* [**Arduino MKR Data Logger**](/building-3d-paws/setting-up-the-data-logger/arduino-mkr)

Detailed sensor wiring diagrams are provided on the corresponding data logger pages.


# Particle IoT

Guide to using Particle Boron and Argon boards as 3D-PAWS data loggers for local data storage, cloud connectivity, and remote station management.

### Overview

The Particle Data Logger is the primary data logger platform used in many 3D-PAWS deployments.

3D-PAWS supports two Particle platforms:

* **Particle Boron** – cellular connectivity
* **Particle Argon** – WiFi connectivity

In a 3D-PAWS station, the Particle data logger:

* collects measurements from connected environmental sensors
* stores time-stamped observations on a microSD card
* transmits observations through the Particle Cloud
* supports remote monitoring and diagnostics
* supports remote firmware updates

The **Boron** is typically used for remote deployments that require cellular connectivity, while the **Argon** can be used where reliable WiFi is available.

***

#### Sensors Supported

The Particle data logger can support the core 3D-PAWS instruments as well as several additional environmental sensors, including:

* rain gauge
* anemometer
* wind vane
* radiation shield sensors for temperature, relative humidity, and pressure
* black globe temperature
* air quality (PM2.5)
* ultrasonic distance measurements for stream level, storm surge, and snow depth
* soil moisture and temperature
* leaf wetness
* light measurements using the legacy light sensor

Actual sensor support depends on the firmware configuration and available data logger connections.

***

#### Assemble the Particle Data Logger

Use the instruction slides and tutorial videos below to assemble the Particle data logger hardware.

**Instruction Slides for Assembling the Data Logger**

{% embed url="<https://docs.google.com/presentation/d/1xGsG8msqOQIqFoJbUwOEQjifbJNcofSw/edit?slide=id.p1#slide=id.p1>" %}

**Tutorial Videos for Assembling the Data Logger**

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf0irfkGBLYU0RNw5N3FuEW5&si=DDDAIk18ajSFqDAR>" %}

{% hint style="info" %}
The video playlist demonstrates the complete assembly process. Use the playlist controls to move between individual assembly videos.
{% endhint %}

***

#### Set Up the Particle Data Logger

After assembling the hardware, use the setup slides below to configure the Particle device and prepare it for use with 3D-PAWS.

**Instruction Slides for Setting Up the Data Logger**

{% embed url="<https://docs.google.com/presentation/d/175zaYxKhs40vupxf09LBYBL99ig3VZSt0cfaWyUmjIc/view?slide=id.g3e9bc05a41f_0_9#slide=id.g3e9bc05a41f_0_9>" %}

***

#### 3D-PAWS Particle Firmware

The current 3D-PAWS Particle firmware is maintained in the **3D-PAWS Particle FullStation GitHub repository**.

[**https://github.com/3d-paws/3D-PAWS-Particle-FullStation**](https://github.com/3d-paws/3D-PAWS-Particle-FullStation)

To download the firmware:

1. Open the repository.
2. Select the green **Code** button.
3. Select **Download ZIP**.

The repository is the primary reference for current firmware releases, configuration information, and firmware documentation.

***

#### Particle Data Logger Wiring

Use the wiring diagram below when connecting sensors and instruments to the Particle data logger.

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FOzqWz7Nd3R7S36eiUN9A%2FParticle_FullStation-20260324.png?alt=media&amp;token=50b91021-616b-47b3-a08b-231c474ce989" alt=""><figcaption></figcaption></figure>

{% hint style="warning" %}
Verify sensor pin assignments and connections before applying power.

The physical connector or data logger pin label does not necessarily identify the signal type.
{% endhint %}

For additional background on Grove, Qwiic, Dupont, I²C, digital pulse, and analog voltage connections, see **Cables and Connectors**.

***

#### Particle Cloud and Remote Management

Particle-based stations use the Particle Cloud for remote communication and device management.

Particle devices support:

* event streaming, including **FS** and **INFO** messages
* remote commands through **DoAction**
* over-the-air firmware updates
* remote device monitoring through the Particle Console
* management of groups or fleets of devices through Particle Products

**Particle Resources**

Use the following Particle resources when configuring or managing a data logger:

* [**Particle Device Setup**](https://setup.particle.io/) – initial device configuration
* [**Particle Status LED and Device Modes**](https://docs.particle.io/troubleshooting/led/) – interpreting device status and connection behavior
* [**Particle Console**](https://docs.particle.io/getting-started/console/console/) – monitoring and managing individual devices
* [**Particle Products**](https://docs.particle.io/getting-started/products/introduction-to-products/#introduction) – managing groups or fleets of 3D-PAWS devices

***

#### Particle Data Logger Architecture

In a Particle-based 3D-PAWS station, observations move from the sensors through the data logger and Particle Cloud before reaching the 3D-PAWS data services.

**Sensors → Particle Data Logger → Particle Cloud → CHORDS → Grafana**

The Particle data logger collects and stores observations locally, while the Particle Cloud provides the communications layer used to transmit data and manage the device remotely.

{% hint style="info" %}
For information about transferring observations from Particle Cloud to CHORDS, see **Particle / CHORDS Integrations**.
{% endhint %}

***

#### Cellular Connectivity and Third-Party SIMs

Particle Boron models provide cellular connectivity for remote deployments.

Cellular compatibility depends on the Boron model and the cellular networks available at the deployment location.

Some deployments may require an external SIM rather than the Particle internal SIM.

→ [**Use a Third-Party SIM with the Boron**](https://docs.google.com/document/d/1fyzIF64ErrC-jGK6rduwHd6FOxpQzs5SD4UBigmqnyI/edit?tab=t.0#heading=h.9lhrwate7irz)

***

#### Firmware Configurations

3D-PAWS Particle firmware can be configured for different monitoring applications and operational requirements.

Configuration may affect:

* measurement intervals
* reporting intervals
* power consumption
* supported sensors
* communications behavior

The latest firmware and configuration documentation should be obtained from the [**3D-PAWS Github repository**](https://github.com/3d-paws).

{% hint style="info" %}
Use the firmware documentation associated with your station configuration rather than assuming that all Particle-based 3D-PAWS stations use the same measurement or reporting intervals.
{% endhint %}

***

#### LoRa Remote Sensors

Particle-based stations can also serve as gateways for remote sensor units that communicate using LoRa.

Remote sensor units using [**Adafruit Feather M0 data loggers**](/building-3d-paws/setting-up-the-data-logger/adafruit-feather-m0) can be used for measurements such as:

* soil moisture and temperature
* precipitation
* stream level
* snow depth

In this configuration, remote sensor units transmit observations over LoRa to a central 3D-PAWS station.

The Particle Boron then forwards those observations through its cellular connection.

This allows sensors to be distributed in locations that do not have direct cellular or WiFi connectivity.

***

#### Power Considerations

Particle data logger power consumption varies with:

* connected sensors
* cellular signal conditions
* measurement frequency
* reporting interval
* firmware configuration
* communications activity

Solar and battery systems should therefore be sized for the specific station configuration and deployment environment.

{% hint style="info" %}
Previously calculated Particle system power values should be treated as planning estimates unless they have been verified through direct measurements on the complete station configuration.
{% endhint %}

See [**Solar Power**](/building-3d-paws/solar-power) for guidance on station power systems.


# Raspberry Pi

Guide to using a Raspberry Pi as a 3D-PAWS data logger for flexible deployments with local logging and optional remote connectivity.

### Overview

The Raspberry Pi is a single-board computer that can be used as a 3D-PAWS data logger when a station requires additional processing capability, local storage, or custom software.

The current 3D-PAWS configuration uses a **Raspberry Pi 3B+ paired with a Grove Base Hat** to connect supported sensors.

In a 3D-PAWS station, the Raspberry Pi can:

* collect measurements from connected environmental sensors
* store observations locally on an SD card
* transmit observations over WiFi or an optional cellular connection
* perform local data processing
* support custom software and sensor integrations

Because the Raspberry Pi runs a full Linux operating system, it provides more processing flexibility than microcontroller-based data loggers, but it also requires substantially more power.

***

#### Sensors Supported

The current 3D-PAWS Raspberry Pi configuration supports:

* rain gauge
* anemometer
* wind vane
* radiation shield sensors for temperature, relative humidity, and pressure
* light sensor

Actual sensor support depends on the installed 3D-PAWS software, hardware interfaces, and available Raspberry Pi connections.

***

#### Assemble the Raspberry Pi Data Logger

Use the instruction slides below to assemble the Raspberry Pi data logger and Grove Base Hat.

**Instruction Slides for Assembling the Data Logger**

{% embed url="<https://docs.google.com/presentation/d/1JU07RYiDDo_5ZBtzBfRU4AUMXfluJfyj/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

***

#### 3D-PAWS Raspberry Pi Software

The software used to operate a Raspberry Pi-based 3D-PAWS station is maintained in the **3D-PAWS Raspberry Pi GitHub repository**.

[**https://github.com/3d-paws/3D-PAWS-Raspberry-Pi**](https://github.com/3d-paws/3D-PAWS-Raspberry-Pi)

The repository contains the Python software used for sensor polling, data logging, and station operation.

{% hint style="info" %}
Use the current GitHub repository as the primary reference for software installation, configuration, and supported functionality.
{% endhint %}

***

#### Raspberry Pi Data Logger Architecture

Unlike Particle-based stations, which use the Particle Cloud as an intermediate communications layer, the Raspberry Pi operates as a local computer and can transmit observations directly to data services.

**Sensors → Raspberry Pi → Local Storage → WiFi / Cellular → CHORDS → Grafana**

The Raspberry Pi can also perform local processing and run custom software before observations are transmitted.

***

#### Connectivity

The Raspberry Pi supports **WiFi connectivity** for locations with an available network.

An optional cellular modem can be added where cellular connectivity is required.

Local storage on the Raspberry Pi's SD card provides a record of observations when network connectivity is unavailable.

{% hint style="info" %}
Communications hardware and configuration depend on the deployment. Verify WiFi or cellular availability at the site before installation.
{% endhint %}

***

#### Power Considerations

Raspberry Pi data loggers require substantially more power than microcontroller-based platforms such as Particle, Adafruit Feather, or Arduino MKR.

Power consumption varies with:

* Raspberry Pi model
* connected sensors
* WiFi or cellular communications
* connected USB devices and peripherals
* processor activity
* software configuration

Because of these higher power requirements, Raspberry Pi stations generally require a larger solar panel and battery system for off-grid deployment.

See [**Solar Power**](/building-3d-paws/solar-power) for guidance on the Raspberry Pi power configuration.

{% hint style="info" %}
Previously calculated Raspberry Pi system power values should be treated as planning estimates unless they have been verified through direct measurements on the complete station configuration.
{% endhint %}

***

#### When to Use a Raspberry Pi

A Raspberry Pi data logger may be appropriate when a station requires:

* advanced local data processing
* custom software
* additional local storage
* specialized sensor integrations
* greater flexibility than a microcontroller-based platform provides

For remote stations where low power consumption and remote device management are the primary requirements, a Particle-based data logger may be more appropriate.


# Adafruit Feather M0

Guide to using Adafruit Feather M0 boards for low-power 3D-PAWS deployments with WiFi, LoRa, or local SD logging.

### Overview

The Adafruit Feather M0 is a compact microcontroller platform used in 3D-PAWS for low-power environmental monitoring and distributed sensor deployments.

Depending on the hardware and firmware configuration, a Feather-based station can:

* collect measurements from connected environmental sensors
* store observations locally on a microSD card
* timestamp observations using a real-time clock (RTC)
* transmit observations over WiFi
* transmit observations over point-to-point LoRa to a central 3D-PAWS gateway
* operate as a LoRaWAN node
* operate as a standalone data logger without network connectivity

Three primary deployment approaches are supported:

* **WiFi** – for sites with reliable wireless network access
* **LoRa / LoRaWAN** – for low-power wireless sensor deployments
* **Local Logging** – for sites where observations are stored locally and retrieved during maintenance visits

***

#### Supported Feather Hardware

The Feather hardware used depends on the communications requirements of the deployment.

For wireless deployments:

* **Adafruit Feather M0 RFM95 LoRa Radio**
* **Adafruit Feather M0 WiFi with ATWINC1500**

For local data logging without network connectivity:

* **Adafruit Feather M0 Adalogger**

The local logging configuration requires a real-time clock to provide accurate timestamps.

Recommended RTC:

* **DS3231**

{% hint style="info" %}
Select the Feather hardware based on the communications available at the deployment site and the role the unit will perform within the observation network.
{% endhint %}

***

#### Sensors Supported

The Feather data logger can support the core 3D-PAWS instruments as well as several additional environmental sensors, including:

* rain gauge
* anemometer
* wind vane
* radiation shield sensors for temperature, relative humidity, and pressure
* black globe temperature
* air quality sensors (PM1.0, PM2.5, PM10)
* ultrasonic distance measurements for stream level, storm surge, and snow depth
* soil moisture and temperature
* leaf wetness
* light sensor

Actual sensor support depends on the Feather hardware, firmware configuration, and available connections.

***

#### Assemble the Feather Data Logger

Use the instruction slides below to assemble the Feather data logger hardware.

**Instruction Slides for Assembling the Data Logger**

{% embed url="<https://docs.google.com/presentation/d/1qhptw_QhshLWI-qKiEvgvAVcz9dJ2Ff-/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=drive_link>" %}

***

#### 3D-PAWS Feather Firmware

The current Feather firmware is maintained in the **3D-PAWS Feather FullStation GitHub repository**.

{% embed url="<https://github.com/3d-paws/3D-PAWS-Feather-FullStation>" %}

The repository contains current firmware versions and configuration information for Feather-based 3D-PAWS systems.

{% hint style="info" %}
Use the GitHub repository as the primary reference for current firmware behavior, supported sensors, measurement intervals, and configuration options.
{% endhint %}

***

#### Feather Wiring

Use the wiring diagram below when connecting sensors and other components to the Feather data logger.

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FQy4gOrazqqdX0ByjswDm%2FFullStation-LoRaWAN_v20260219.png?alt=media&amp;token=119f6405-9f22-435f-a8e6-17d56d1f6a0c" alt=""><figcaption></figcaption></figure>

{% hint style="warning" %}
Verify sensor pin assignments and wiring before applying power.

The connector type or data logger pin label does not necessarily identify the signal type.
{% endhint %}

For background on Grove, Qwiic, Dupont, I²C, digital pulse, and analog voltage connections, see **Cables and Connectors**.

***

#### Feather Data Logger Architecture

Feather-based systems collect observations locally and then either store or transmit them depending on the selected configuration.

A typical network-connected data flow is:

**Sensors → Feather Data Logger → Local Storage → Communications Network → Data Service**

The communications path depends on whether the station is using WiFi, point-to-point LoRa, LoRaWAN, or local-only logging.

***

#### WiFi Configuration

A WiFi Feather can be used where reliable wireless network infrastructure is available.

In this configuration:

* the Feather collects sensor observations
* observations are stored locally
* data is transmitted through WiFi to the configured data service

This configuration is best suited to stations located near reliable network infrastructure.

***

#### LoRa and LoRaWAN Communication

Feather-based 3D-PAWS systems can use LoRa radio communication in two different ways:

* **LoRaWAN Node** – communication through a compatible LoRaWAN gateway and network
* **LoRa Remote Unit** – point-to-point communication with a central 3D-PAWS gateway&#x20;

These configurations may use similar radio hardware, but they differ in how observations are transmitted and routed.

***

#### LoRaWAN Node

In the **LoRaWAN Node** configuration, the Feather communicates with a compatible LoRaWAN gateway rather than directly with a 3D-PAWS Particle gateway.

A typical data path is:

**Sensors → Feather LoRaWAN Node → LoRaWAN Gateway → LoRaWAN Network / Data Service**

The exact path from the LoRaWAN network to the final data service depends on the network and integration being used.

{% hint style="info" %}
A LoRaWAN deployment requires compatible LoRaWAN gateway and network infrastructure. This is different from the 3D-PAWS LoRa Remote Unit configuration, which sends observations directly to a central 3D-PAWS gateway.
{% endhint %}

***

#### LoRa Remote Unit

In the **LoRa Remote Unit** configuration, the Feather acts as a remote sensing node.

The remote unit:

* collects observations from one or more connected sensors
* transmits observations over a point-to-point LoRa radio link
* sends the observations to a central 3D-PAWS station

A Particle Boron equipped with a LoRa receiver is typically used as the central gateway.

The data flow is:

**Remote Sensors → Feather LoRa Remote Unit → LoRa Radio Link → Particle Boron Gateway → Particle Cloud → CHORDS → Grafana**

This configuration is useful for distributed sensor networks where individual sensor locations do not have direct WiFi or cellular connectivity.

Typical remote measurements may include:

* soil moisture and temperature
* precipitation
* stream level
* snow depth

{% embed url="<https://github.com/3d-paws/3D-PAWS-Feather-LoRa-Remote>" %}

**Instruction Slides for Assembling the Particle LoRa Receiver Harness**

{% embed url="<https://docs.google.com/presentation/d/1ikMxvqIxJEzOZv5xA4qClWeySDBqD1eZ/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=drive_link>" %}

***

#### Radio Frequency Considerations

LoRa and LoRaWAN radio frequencies are regulated differently by country and region.

Verify that the selected Feather radio hardware, frequency band, and operating configuration comply with local spectrum regulations before deployment.

***

#### Local Logging Configuration

Where network connectivity is unavailable, the Feather can operate as a standalone data logger.

In this configuration:

* observations are collected from connected sensors
* data is stored locally on the microSD card
* the RTC provides observation timestamps
* no network connection is required
* observations are retrieved manually during maintenance visits

This configuration can be useful for remote monitoring sites where communications infrastructure is unavailable.

***

#### Power Considerations

Feather-based systems are designed for low-power environmental monitoring.

Actual power consumption depends on:

* the Feather board being used
* connected sensors
* WiFi, LoRa, or LoRaWAN communications
* measurement and reporting intervals
* firmware configuration

Low power requirements make Feather systems particularly useful for remote sensor nodes and distributed monitoring networks.

***

#### When to Use a Feather

A Feather-based data logger may be appropriate when a deployment requires:

* very low power consumption
* point-to-point LoRa communication
* LoRaWAN connectivity
* distributed remote sensor nodes
* standalone local data logging
* a compact microcontroller-based system

For stations that require direct cellular connectivity and extensive remote device management, a Particle-based data logger may be more appropriate.


# Arduino MKR

Guide to using Arduino MKR boards as low-power 3D-PAWS data loggers with local SD storage and optional cellular transmission.

### Overview

The Arduino MKR is a microcontroller-based data logger platform used in 3D-PAWS for compact, low-power environmental monitoring deployments.

The MKR platform can:

* collect measurements from connected environmental sensors
* timestamp observations
* store observations locally on a microSD card
* transmit observations over a cellular network
* continue storing observations locally when cellular connectivity is temporarily unavailable

The 3D-PAWS MKR implementation typically uses one of the following boards:

* **Arduino MKR NB 1500** – LTE / NB-IoT cellular connectivity
* **Arduino MKR GSM 1400** – GSM cellular connectivity

Supporting components may include:

* microSD card for local data storage
* real-time clock (RTC)
* cellular SIM card
* cellular antenna
* EEPROM memory

{% hint style="info" %}
Cellular network compatibility varies by country, carrier, and MKR board. Verify network availability and SIM compatibility for the deployment location before selecting a data logger.
{% endhint %}

***

#### Sensors Supported

The MKR data logger can support the core 3D-PAWS instruments as well as several additional environmental sensors, including:

* rain gauge
* anemometer
* wind vane
* radiation shield sensors for temperature, relative humidity, and pressure
* black globe temperature
* air quality sensors (PM1.0, PM2.5, PM10)
* ultrasonic distance measurements for stream level, storm surge, and snow depth
* soil moisture and temperature
* leaf wetness
* light sensor

Actual sensor support depends on the installed firmware, hardware configuration, and available data logger connections.

***

#### Assemble the MKR Data Logger

Use the instruction slides below to assemble the Arduino MKR data logger hardware.

**Instruction Slides for Assembling the Data Logger**

{% embed url="<https://docs.google.com/presentation/d/1hOtuYt_uVrD-8RlnOs4yGO56pUlioobT/view>" %}

***

#### 3D-PAWS MKR Firmware

The current MKR firmware is maintained in the **3D-PAWS MKR FullStation GitHub repository**.

{% embed url="<https://github.com/3d-paws/3D-PAWS-MKR-FullStation>" %}

The repository contains:

* station firmware
* configuration parameters
* sensor interface libraries
* hardware pin mappings

{% hint style="info" %}
Use the current GitHub repository as the primary reference for firmware behavior, supported sensors, configuration parameters, and hardware pin assignments.
{% endhint %}

***

#### MKR Wiring

Use the wiring diagram below when connecting sensors and other station components to the MKR data logger.

<figure><img src="https://3872952369-files.gitbook.io/~/files/v0/b/gitbook-x-prod.appspot.com/o/spaces%2FOPo6sjPamohjSzU18zL8%2Fuploads%2FXuSfBby3kBK2PwoNJPFU%2FMKR1500-v260324.png?alt=media&amp;token=c073fd96-5057-4827-9121-a1f81669cf5e" alt=""><figcaption></figcaption></figure>

{% hint style="warning" %}
Verify sensor pin assignments and wiring before applying power.

The connector type or data logger pin label does not necessarily identify the signal type.
{% endhint %}

For background on Grove, Qwiic, Dupont, I²C, digital pulse, and analog voltage connections, see **Cables and Connectors**.

***

#### MKR Data Logger Architecture

In a typical cellular MKR deployment, observations are collected by the data logger, stored locally, and transmitted through the cellular network to the 3D-PAWS data services.

**Sensors → Arduino MKR Data Logger → Local Storage → Cellular Network → CHORDS → Grafana**

Local microSD storage helps preserve observations when cellular connectivity is temporarily unavailable.

***

#### Cellular Connectivity

Remote data transmission requires:

* a compatible MKR cellular board
* an active SIM card
* an appropriate cellular antenna
* cellular coverage at the deployment site
* correct network and firmware configuration

{% hint style="info" %}
Confirm cellular connectivity at or near the proposed deployment location before installing the station. Network availability can vary significantly by carrier and location.
{% endhint %}

***

#### Power Considerations

Arduino MKR boards are designed for relatively low-power microcontroller applications and can be suitable for solar-powered 3D-PAWS deployments.

Actual power consumption depends on:

* the MKR board being used
* cellular network conditions
* connected sensors
* measurement and reporting intervals
* firmware configuration
* cellular transmission activity


# Solar Power

Guidance for sizing, placing, and mounting solar power systems for Particle, Feather, and Raspberry Pi stations.

3D-PAWS stations are designed for remote, off-grid deployment and rely on solar energy for continuous operation. Using solar power enables long-term data collection without frequent site visits, but it also means that proper panel sizing, placement, and orientation are critical to system reliability.

Depending on the data logger used, the 3D-PAWS system supports multiple solar power configurations with different power requirements. This page describes the supported solar setups and provides guidance on mounting and orienting the solar panel for reliable operation.

***

### Solar Power Configurations

The 3D-PAWS system currently supports two distinct solar power configurations, tailored to the power needs of each data logger.

#### Particle Boron or Adafruit Data Logger

The Particle Boron data logger uses a low-power solar configuration consisting of:

* A **5W, 6V Voltaic solar panel** (ETFE-coated, IP67-rated)
* A **V50 USB battery pack** for energy storage

This setup provides approximately **6.12V peak voltage** and **\~940 mA current**, which is sufficient for low-power cellular data logging. The battery pack supports overnight operation, while the panel’s **50 cm waterproof cable** simplifies outdoor mounting.

This configuration is well-suited for long-term, low-maintenance deployments where power consumption is minimal.

#### Raspberry Pi Data Logger

The Raspberry Pi 3B+ requires a higher-power solar setup due to its increased energy demand. This configuration includes:

* A **20W, 12V solar panel**
* A **12V battery** for energy storage
* A **charge controller** (PWM or MPPT) to prevent overcharging
* A **buck converter** to step down 12V to **5V / 2A** for the Raspberry Pi

This setup accounts for the Raspberry Pi’s approximate **5.25W power consumption** and supports additional peripherals such as Grove sensors or cellular modems. A **low-voltage cutoff** is recommended to protect the battery during extended low-sun conditions.

> **Note:** Both solar configurations benefit from careful panel placement and orientation, particularly during winter or in locations with limited sunlight.

***

### Solar Panel Placement

Before setting the panel angle, ensure the panel is installed in a location with:

* **Minimal shading** throughout the day
* Clear exposure to the sun, especially during midday hours
* A **stable and secure mount** that can withstand wind and weather

Shading and poor placement often have a larger impact on performance than small errors in tilt angle.

> **Field Tip:** Even partial shading on a solar panel can significantly reduce power output. Always prioritize shade-free placement over fine angle adjustments.

***

### Optimal Solar Panel Tilt Angle

To maximize energy production, the solar panel should be mounted at an appropriate tilt angle. The optimal tilt depends primarily on your **geographic location**, specifically your **latitude**, and can be adjusted to improve seasonal performance.

#### Why Tilt Matters

Solar panels produce the most power when sunlight strikes the panel **perpendicularly**. Setting the panel at an appropriate tilt increases the total sunlight received throughout the day and can significantly improve charging performance — especially in regions where the sun’s elevation changes with the seasons.

#### Simple Guidelines for Setting Panel Angle

**Fixed (Year-Round) Mount**

For a fixed installation that will not be adjusted:

* Set the panel tilt angle approximately **equal to your latitude**
* This provides good performance across all seasons with minimal effort

This approach is recommended for most deployments where reliability and simplicity are priorities.

**Seasonal Adjustment (Optional)**

If the panel mount allows for occasional adjustment, seasonal tuning can improve performance:

* **Summer:** set tilt to *latitude minus 10–15°*
* **Winter:** set tilt to *latitude plus 10–15°*
* **Spring/Fall:** set tilt close to your latitude

> **Note:** Seasonal adjustment is optional. Small deviations from the ideal angle typically have a modest impact compared to shading, placement, or panel size.

***

### Next Steps

Once the solar panel is mounted and oriented, proceed to the build instructions for your selected data logger configuration. The following sections provide step-by-step guidance for assembling and wiring each solar power system.

### Instruction Slides for Assembling the Solar Panel Mount

{% embed url="<https://docs.google.com/presentation/d/18Er8UwX-Hanuhl_8i3VHRSBnsjpwIZb3/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=drive_link>" %}

### Video Tutorial

This video demonstrates how to build the solar panel mount for the Particle Data Logger. There is only one video in this playlist.

{% embed url="<https://www.youtube.com/watch?list=PL_rvcKZhmIf0QEU8CHnWftkNOTpdW5t_7&v=BJxDNZ5akLE>" %}
Small Solar Panel Mount - Video Tutorial
{% endembed %}

### Solar Panel Mount Option for Larger Solar Panels

{% embed url="<https://docs.google.com/presentation/d/1qEKXb9IAtZ79u-Bk_NxLLnpCQMatPkd8/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}


# Pre-Assemble the Weather Station

Guide to assembling, testing, and preparing a 3D-PAWS station for transport before field deployment.

Before deploying a 3D-PAWS station in the field, the system should be fully assembled and tested in a workshop, laboratory, or other controlled environment. Pre-assembly ensures that all components function correctly before installation and reduces troubleshooting time at the deployment site.

Testing the station before deployment allows technicians to verify sensor operation, confirm wiring, and identify configuration issues while tools and replacement parts are readily available.

***

## Objectives of Pre-Assembly

Pre-assembly and testing help confirm that:

* all sensors initialize correctly
* cables and connectors are properly installed
* the data logger is operating and communicating correctly
* sensor values appear reasonable
* the power system is functioning properly

Completing these checks before traveling to the field helps prevent installation delays and ensures that stations can be deployed efficiently.

***

## Assemble the Station

During pre-assembly, the station should be built in the same configuration that will be used in the field.

Typical steps include:

* assembling the station frame or mast
* installing the radiation shield and environmental sensors
* installing wind sensors and the rain gauge
* mounting the data logger enclosure
* connecting all sensor cables and I²C connectors
* installing the solar panel and battery system

Refer to the instrument assembly pages for detailed instructions:

* Rain Gauge Assembly
* Radiation Shield Assembly
* Anemometer
* Wind Vane Assembly
* Solar Panel Mount

***

## Test the Sensors

After the station is assembled, verify that all sensors are functioning correctly.

Typical checks include:

* confirming the station powers on
* verifying that sensor readings appear in the data logger output
* checking that wind sensors rotate freely
* verifying that the rain gauge registers tipping events
* confirming temperature, humidity, and pressure values are reasonable

See:\
**Testing the Sensors**

***

## Verify Data Logging and Communications

Confirm that the station is correctly logging and transmitting data.

Typical checks include:

* verifying the data logger is online
* confirming sensor data appears in the console or data platform
* confirming correct station configuration and firmware
* verifying that timestamps and reporting intervals are correct

See:

* Data Logger – Particle
* Data Logger – Raspberry Pi
* Data Access and Visualization

***

## Prepare the Station for Transport

After testing is complete, the station should be partially disassembled for safe transport.

Typical preparation steps include:

* removing delicate sensors if necessary
* securing cables and connectors
* protecting sensors from impact during transport
* organizing tools and hardware needed for field installation

Keeping components organized during transport makes reassembly in the field easier and reduces the risk of lost parts.

***

### Instruction Slides for Building the Weather Station

> **NOTE**: This section is being updated from building and installing the station to pre-assembling in the lab. The slide deck will be split into two sections and updated soon.

{% embed url="<https://docs.google.com/presentation/d/1J0h492ZZXzT3DvGdZJpfZMPuBFz6XeMU/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

### Tutorial Videos for Building the Weather Station

This video is part of a playlist that demonstrates building the 3D-PAWS station. You can toggle between videos using the list icon at the top right or by using the "fast forward" button at the bottom left.

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf2ghMmTFsVr0xDhl8QTbxDd&si=Pcy08ltywOhcamxp>" %}

***

## Next Step

Once the station has been assembled and tested, it can be transported to the installation site for deployment.

See: [**Field Installation and Deployment**](broken://pages/2sezPqyFzT9382oLq8c6)


# Deploying 3D-PAWS

Guidance for selecting a site, installing and verifying the station, aligning wind measurements, and documenting the deployment.

### Overview

Deploying a 3D-PAWS station involves more than physically installing the equipment. Proper site selection, instrument placement, system verification, and documentation are essential for producing reliable and representative observations.

Use the pages in this section to move through the deployment process from site selection through final documentation.

***

#### Deployment Workflow

**1. Site Selection**

Choose a location that provides representative environmental conditions, appropriate instrument exposure, adequate solar access and communications, and safe access for installation and maintenance.

→ [**Site Selection**](/deploying-3d-paws/site-selection)

**2. Field Installation**

Install and secure the pre-assembled station, instruments, power system, and supporting equipment.

Use the **3D-PAWS Installation Checklist** during deployment to guide installation and final field checks.

→ [**Field Installation and Deployment**](/deploying-3d-paws/field-installation-and-deployment)

→ [**3D-PAWS Installation Checklist**](https://docs.google.com/document/d/1--PBiW-t_eiH6AI-fDY2usEfYwW2dc-Q79F7PT1GA9w/view?tab=t.0#heading=h.aowdo0rqk9y6)

**3. Wind Vane Alignment**

Align the wind vane to **true north** so that wind direction measurements are referenced correctly.

→ [**Wind Vane Alignment**](/deploying-3d-paws/wind-vane-alignment)

**4. System Verification**

Before leaving the site, verify that the station is powered, sensors are operating, communications are functioning, and observations are reaching the expected data service.

System verification is included as part of the **Field Installation and Deployment** procedure and Installation Checklist.

→ [**Field Installation and Deployment**](/deploying-3d-paws/field-installation-and-deployment)

**5. Station Metadata**

Record the station location, configuration, instrument heights, site conditions, photographs, and known siting limitations using the 3D-PAWS metadata documentation.

→ [**Station Metadata**](/deploying-3d-paws/station-metadata)

→ [**3D-PAWS Metadata Form**](https://docs.google.com/document/d/1q_UKSZHwp8ADDljWSyT0m7x3b6vQNsZgFbbu2g5cdOE/view?tab=t.0#heading=h.ju4qxs8rykjh)

***

#### Observing Practices and Standards

For deployment and instrument siting, refer to [**Volume I – Measurement of Meteorological Variables**](https://library.wmo.int/records/item/68695-guide-to-instruments-and-methods-of-observation?offset=3) of WMO-No. 8, particularly the guidance for the environmental variable being measured.

{% hint style="info" %}
3D-PAWS do not always follow the standard instrument heights or configurations described in WMO guidance. For example, wind sensors in a typical 3D-PAWS configuration are installed at approximately **2 m above ground level**, rather than the 10 m height commonly used for standard surface wind observations.

Document these installation characteristics in the station metadata so observations can be interpreted appropriately.
{% endhint %}


# Site Selection

Guidance for choosing a deployment site with representative exposure, safe access, and minimal measurement interference.

### Overview

Selecting an appropriate site is one of the most important factors in ensuring high-quality observations from a 3D-PAWS station. Even when sensors are functioning correctly, poor siting can result in measurements that are biased or not representative of local conditions.

Site selection should prioritize **exposure, representativeness, practical constraints, and instrument-specific siting requirements**.

***

### Key Considerations

When selecting a site, evaluate these factors:

* **Exposure** – Are sensors unobstructed by buildings, trees, or terrain?
* **Representativeness** – Does the site reflect the surrounding environment you want to measure?
* **Solar Access** – Will the solar panel receive sufficient sunlight throughout the day?
* **Communications** – Is cellular or WiFi connectivity available and reliable?
* **Security** – Is the site protected from theft, vandalism, or accidental damage?
* **Accessibility** – Can the station be safely installed and maintained over time?

***

### Instrument Siting Guidelines

Different instruments have different siting requirements. Consider these when selecting a location.

| Instrument       | Key Considerations                                                         |
| ---------------- | -------------------------------------------------------------------------- |
| Rain Gauge       | Open exposure, free-falling precipitation, away from irrigation and runoff |
| Wind Sensors     | Minimal obstructions, consider prevailing winds and obstacle distance      |
| Radiation Shield | Good airflow, no shading, away from heat sources                           |
| Solar Panel      | Maximum sun exposure throughout the day                                    |
| Soil Sensors     | Representative soil conditions and minimal disturbance                     |

***

#### Rain Gauge

* Place in an open area
* Avoid obstructions such as trees, buildings, towers, and other structures
* Ensure precipitation can fall freely into the gauge
* Avoid locations where water may drip or flow into the gauge from overhead objects, including tree branches, roofs, overhangs, and nearby structures
* Avoid locations influenced by artificial irrigation, including sprinklers and irrigation systems
* Keep clear of roof runoff, drainage systems, and other non-natural water sources

***

#### Wind Sensors

* Install with minimal obstruction
* Avoid areas where airflow is blocked or channeled
* Consider prevailing wind direction
* Whenever possible, maintain a distance from obstacles of at least 30 times the obstacle height (30:1 rule) to minimize turbulence and flow distortion
* Avoid nearby buildings, trees, towers, and other structures that may alter wind measurements

> **Example:** A 10 m tree should ideally be at least 300 m from the wind sensor.

***

#### Radiation Shield (Temperature / Humidity / Pressure)

* Install in well-ventilated air
* Avoid shaded or enclosed areas
* Avoid heat sources such as buildings, pavement, and bodies of water
* Ensure the sensor is exposed to representative ambient conditions

***

#### Solar Panel

* Ensure maximum sun exposure throughout the day
* Avoid shading from objects or terrain
* Consider seasonal changes in sun angle
* Position the panel for optimal solar exposure based on local latitude and hemisphere

***

#### Soil Sensors (if installed)

* Place in representative soil conditions
* Avoid artificially shaded or disturbed areas
* Avoid locations affected by irrigation unless irrigation monitoring is an objective of the deployment

***

### Balancing Siting Tradeoffs

Perfect sites are rare. In many deployments, it may not be possible to meet all siting recommendations simultaneously.

When compromises are required:

* prioritize rain gauge and wind sensor exposure
* maintain good airflow around temperature and humidity sensors
* ensure adequate solar power and communication for reliable operation
* document any known limitations that may affect observations

Record all siting limitations in the station metadata.

***

### Observing Practices and Standards

3D-PAWS follows guidance from the [**World Meteorological Organization (WMO) Guide to Instruments and Methods of Observation (WMO-No. 8)**](https://community.wmo.int/site/knowledge-hub/programmes-and-initiatives/instruments-and-methods-of-observation-programme-imop/guide-instruments-and-methods-of-observation-wmo-no-8-0), which provides detailed recommendations for sensor exposure, siting, and measurement practices.

Applying these principles improves data quality, consistency, and comparability with other observing networks.

***

### Summary

A well-chosen site will:

* minimize measurement bias
* improve data reliability
* reduce troubleshooting needs
* support long-term station operation and maintenance

Site selection is a critical step that directly affects the quality and value of the observations collected.

***

### Instruction Slides for Site Selection

{% embed url="<https://docs.google.com/presentation/d/1ussaCbaoW50Qv_-ZaJyT3yiOg53w-B-s/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}


# Field Installation and Deployment

Guide to installing a pre-assembled 3D-PAWS station in the field and verifying that it is ready for operation.

### Overview

Field installation begins after the station has been assembled, configured, and tested.

The deployment process on this page is organized into three stages:

1. **Prepare the Site**
2. **Install the Station**
3. **Verify the Installation**

Use the **3D-PAWS Installation Checklist** throughout the deployment to confirm that required installation and verification steps are completed before leaving the site.

***

#### Installation Checklist

The [**3D-PAWS Installation Checklist**](https://docs.google.com/document/d/1--PBiW-t_eiH6AI-fDY2usEfYwW2dc-Q79F7PT1GA9w/edit?usp=sharing) provides a field reference for:

* preparing the installation area
* installing and securing the station
* checking instrument placement
* verifying power and communications
* confirming sensor operation
* recording required site information

{% hint style="info" %}
Use the checklist during the installation rather than relying on memory. Complete all applicable checks before leaving the site.
{% endhint %}

***

#### Instruction Slides for Installing the Weather Station

> **NOTE:** This section is being updated from building and installing the station to just installation after pre-assembly in the lab. The slide deck will be split into two sections and updated soon.

{% embed url="<https://docs.google.com/presentation/d/1J0h492ZZXzT3DvGdZJpfZMPuBFz6XeMU/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

Use these slides for the step-by-step procedure for installing the pre-assembled station structure and instruments in the field.

**Tutorial Videos for Installing the Weather Station**

> This video is part of a playlist that demonstrates building the 3D-PAWS station. You can toggle between videos using the list icon at the top right or by using the "fast forward" button at the bottom left.

{% embed url="<https://youtube.com/playlist?list=PL_rvcKZhmIf2ghMmTFsVr0xDhl8QTbxDd&si=Pcy08ltywOhcamxp>" %}

***

### Prepare the Site

Before installing the station, confirm that the selected location still meets the requirements identified during site selection.

Check that the installation area provides:

* appropriate exposure for the instruments
* sufficient solar access
* reliable communications coverage
* safe access for installation and maintenance
* adequate security
* stable ground or mounting conditions

For detailed instrument exposure and siting requirements, see [**Site Selection**](/deploying-3d-paws/site-selection).

{% hint style="warning" %}
If field conditions differ significantly from the original site assessment, reevaluate the location before installing the station.
{% endhint %}

#### Prepare the Installation Area

Before mounting the station:

* clear only the vegetation or debris necessary for safe installation
* identify underground utilities or other hazards before driving posts or anchors
* confirm that the mounting location is stable
* organize tools, hardware, and station components before beginning installation
* verify that the station can be positioned without creating unnecessary obstructions around the sensors

***

### Install the Station

Install and secure the station using the procedure shown in the installation slides.

After installation, confirm that:

* the station structure is stable
* vertical supports are properly positioned
* instruments and mounting arms are secure
* the rain gauge is level
* cables are routed and protected from strain
* connectors are fully seated
* the solar panel and battery system are connected
* all enclosures are closed and protected from weather

{% hint style="info" %}
Mechanical stability is part of good instrument siting. A station that shifts, tilts, or vibrates can affect measurements and increase wear on components.
{% endhint %}

***

#### Instrument Placement

Instrument placement should follow the requirements established during **Site Selection**.

During installation, perform a final check of each instrument.

**Rain Gauge**

Confirm that the rain gauge:

* is level
* has an unobstructed opening
* is clear of overhead dripping or runoff
* is not exposed to sprinklers or other artificial irrigation
* is securely mounted

**Wind Sensors**

Confirm that the anemometer and wind vane:

* rotate freely
* are securely mounted
* have the best available exposure to the surrounding airflow
* are not unnecessarily obstructed by the station structure or nearby objects

The wind vane must also be aligned to **true north**.

→ See [**Wind Vane Alignment**](/deploying-3d-paws/wind-vane-alignment)

**Radiation Shield**

Confirm that the radiation shield:

* is exposed to freely circulating ambient air
* is not directly affected by nearby heat sources
* is securely mounted
* is positioned according to the selected siting configuration

**Solar Panel**

Confirm that the solar panel:

* has clear exposure to sunlight
* is securely mounted
* is oriented according to the selected solar configuration
* is not shaded by the station or nearby objects

For detailed power-system guidance, see **Solar Power**.

***

### Verify the Installation

Before leaving the site, verify that the complete station is operating correctly.

#### Power and Communications

Confirm that:

* the data logger powers on normally
* the battery and solar system are connected
* the data logger connects to the expected network
* observations are being transmitted when communications are available

#### Sensor Operation

Confirm that:

* all expected sensors are detected
* sensor values are updating
* measurements are physically reasonable for current conditions
* the rain gauge and anemometer respond when manually tested, where appropriate
* wind direction changes appropriately when the vane is rotated

{% hint style="info" %}
If observations are missing, unexpected, or unrealistic, use the **Troubleshooting** guidance before leaving the site whenever possible.
{% endhint %}

#### Verify Data at the Data Service

If network connectivity is available, confirm that new observations appear in the configured data service or dashboard.

Check:

* observation timestamps
* expected reporting frequency
* expected sensor variables
* reasonable measurement values

This confirms the complete path from the sensor through the data logger and communications system to the data service.

***

#### Record Station Metadata

After the installation is complete, document the site and station configuration.

Record information such as:

* station location and elevation
* instrument heights
* station orientation
* data logger and communications configuration
* power-system configuration
* site conditions
* installation photographs
* known siting limitations

Do not duplicate the full metadata procedure here.

→ See [**Station Metadata**](/deploying-3d-paws/station-metadata) for the complete metadata form and documentation requirements.

***

#### Before Leaving the Site

Complete one final walk-around and confirm that:

* the station is stable and secure
* all hardware is tightened
* all cables are protected
* instruments are correctly positioned
* the wind vane is aligned
* the station is powered
* communications are functioning where available
* observations are updating
* metadata and installation photographs have been recorded
* tools, packaging, and installation debris have been removed from the site


# Wind Vane Alignment

Instructions for aligning the wind vane to true north using solar noon or a compass with magnetic declination.

Accurate wind vane alignment to **true north** (geographic north) is critical for reliable meteorological and wind turbine data. Misalignment introduces errors in wind direction measurements.

#### Option 1: **Aligning to True North with a Solar Noon Shadow**

Use the [NOAA Solar Calculator](https://gml.noaa.gov/grad/solcalc/) tool to determine solar noon for your location (in coordinates) at the current date and time. Then follow the slideshow below and use the alignment cap to determine true north.

#### **Option 2: Aligning with a Compass and Magnetic Declination**

If you use a compass to align your wind vane, remember that a compass points to magnetic north, not true (geographic) north. The difference between these directions is called ***magnetic declination***, which varies by location and changes over time. To ensure accurate alignment:

* **Find your local magnetic declination** ([NOAA provides an online calculator](https://www.ngdc.noaa.gov/geomag/calculators/magcalc.shtml)).
* **Adjust your compass reading**:
  * If your declination is *east* (positive), subtract the declination value from your compass bearing.
  * If your declination is *west* (negative), add the declination value to your compass bearing.
* Set the wind vane so it points to the *adjusted* bearing for true north, not the uncorrected compass north.

For example, if your magnetic declination is 10° east, and your compass points to 0° (magnetic north), align the wind vane to 350° (0° – 10°) to achieve true north. If your declination is 10° west, align to 10° (0° + 10°).

### Solar Noon Instruction Slides

{% embed url="<https://docs.google.com/presentation/d/1BeCbO4roiUy_lj_0uDC8EfB9S0nw7K6W/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}


# Station Metadata

Guide to recording post-installation metadata, site conditions, and station configuration for long-term data quality and traceability.

The [**3D-PAWS Metadata Form**](https://docs.google.com/document/d/1q_UKSZHwp8ADDljWSyT0m7x3b6vQNsZgFbbu2g5cdOE/edit?tab=t.0) is used to record essential information about each station following installation. It captures key details such as station identity, geographic coordinates, power configuration, communications setup, and sensor placement. This metadata ensures that all 3D-PAWS stations are documented consistently, allowing for reliable data interpretation, troubleshooting, and long-term network management.

Technicians should complete the form immediately after installation, including photographs, alignment notes, and power or communications verification. Accurate metadata supports future maintenance, calibration, and data validation by linking environmental observations to precise site conditions and installation parameters.

#### **Why It Matters**

Post-installation metadata is as important as the sensor data itself. Site conditions, instrument heights, alignment, and power/communications details directly affect how observations should be interpreted, compared, and quality-controlled across the network. Without this context, it becomes difficult to distinguish real environmental signals from installation-related biases or later site changes.

This form also supports **station traceability and interoperability**, including reporting to frameworks like **WIS 2.0** through a WMO identifier. Consistent metadata makes each 3D-PAWS station reproducible, easier to maintain over time, and more valuable for shared research and operational datasets.


# Accessing the Data

Guidance for accessing and verifying 3D-PAWS observations through CHORDS and Grafana.

### Overview

3D-PAWS stations transmit environmental observations through connected data services for storage, visualization, analysis, and integration into observation systems.

***

#### Data Flow

**Sensors → Data Logger → Network → CHORDS → Grafana**

* **CHORDS** stores and provides access to station observations.
* **Grafana** provides dashboards for viewing current and historical observations.

{% hint style="info" %}
The exact data path depends on the data logger and communications configuration. For example, Particle-based stations transmit observations through the Particle Cloud before they reach CHORDS.
{% endhint %}

***

#### Viewing Data

| Platform    | Purpose                 | Key Features                                                 |
| ----------- | ----------------------- | ------------------------------------------------------------ |
| **CHORDS**  | Data storage and access | Time-series observations, API access, external integration   |
| **Grafana** | Data visualization      | Current conditions, historical data, customizable dashboards |

Use the pages in this section for detailed instructions on accessing and working with each platform.

→ [**CHORDS**](/accessing-the-data/chords)

→ [**Grafana**](/accessing-the-data/grafana)

***

#### Verify Station Data

After deployment or maintenance, confirm that observations are reaching the data service and updating as expected.

Check that:

* new observations are being received
* timestamps are correct
* observations are updating at the expected frequency
* all expected sensor variables are present
* measurement values are physically reasonable for current conditions

#### Basic Data Quality Checks

When reviewing station data, look for patterns that are consistent with how each measurement should behave.

| Measurement           | What to Look For                                                                                                                                                |
| --------------------- | --------------------------------------------------------------------------------------------------------------------------------------------------------------- |
| **Temperature**       | A recognizable day/night cycle without abrupt, unexplained jumps                                                                                                |
| **Relative Humidity** | Changes that generally respond to temperature and changing moisture conditions; watch for values persistently near 0% or 100%                                   |
| **Pressure**          | Smooth changes over time; abrupt jumps or flat values may indicate a problem                                                                                    |
| **Rainfall**          | Zero during dry periods and discrete increases during precipitation events; accumulation should not increase because of irrigation or other non-weather sources |
| **Wind Speed**        | Natural variability over time; extended periods of exactly zero may indicate a broken anemometer                                                                |
| **Wind Direction**    | Direction should vary with changing winds; a fixed value for long periods may indicate a broken vane or connection issue if wind speeds are present.            |

***

#### If Data Is Missing or Incorrect

If observations are missing, incomplete, or unexpected, begin with the basic station checks:

1. Verify that the data logger is powered and operating.
2. Confirm network connectivity.
3. Check sensor and cable connections.
4. Verify the station configuration.
5. Confirm that observations are reaching the expected data service.

{% hint style="info" %}
For Particle-based stations, **INFO messages** provide a useful first check of data logger status, connected sensors, storage, communications, and other system conditions.
{% endhint %}

For detailed diagnostic procedures, see **Troubleshooting**.

***

#### Pages in This Section

* **CHORDS** – accessing stored station observations and data services
* **Grafana** – viewing station observations and dashboards
* **Particle / CHORDS Integrations** – configuring the data path between Particle Cloud and CHORDS


# CHORDS

Guide to accessing, reviewing, and downloading 3D-PAWS observations stored in CHORDS.

### Overview

CHORDS (Cloud-Hosted Real-time Data Services for the Geosciences) is the primary data storage and access platform used by 3D-PAWS.

For 3D-PAWS stations, CHORDS provides:

* storage of time-series observations
* access to current and historical station data
* organization of stations and instruments
* data access through web services and APIs
* integration with visualization tools such as Grafana

A CHORDS portal can contain observations from multiple 3D-PAWS stations and monitoring networks.

***

#### **Accessing a CHORDS Portal**

3D-PAWS observation networks are typically hosted on dedicated CHORDS portals. Countries or projects may operate their own portal for accessing and managing station data.

Open the CHORDS portal associated with your station or observation network.

Within CHORDS, stations and their observations are organized by **sites** and **instruments**.

Use the portal to locate the appropriate station and review the observations being received from that instrument.

{% hint style="info" %}
CHORDS portal URLs vary by country or project. Use the portal URL provided for your observation network.
{% endhint %}

**Example CHORDS Portal:** [View an example 3D-PAWS CHORDS portal](https://3d.chordsrt.com/)

***

#### Using CHORDS

Use CHORDS to:

* confirm that station observations are being received
* review current and historical observations
* check observation timestamps
* identify gaps in transmitted data
* access observations for additional analysis
* download station data

For graphical dashboards and visualization of observations, see **Grafana**.

***

#### CHORDS Training

The training slides below provide a walkthrough of using CHORDS with a 3D-PAWS system.

{% embed url="<https://docs.google.com/presentation/d/1RpbUyV8Wjgr9eI1tToozGk37hvOjPIM5la5GQ1Wm29w/edit?usp=sharing>" %}
Click the dots icon to enlarge by entering full screen
{% endembed %}

{% hint style="info" %}
Use the presentation controls to open the slides in full screen for easier viewing.
{% endhint %}

***

#### Detailed CHORDS Guide

For a more detailed walkthrough of the CHORDS interface, portal setup, and available resources, use the **CHORDS Introduction** guide below.

{% embed url="<https://docs.google.com/document/d/1FbDuxSaUOrkOubAsJqw1zbSVJCGgxhQau08r9AlbykY/edit?usp=sharing>" %}
Follow this link to enlarge: <https://docs.google.com/document/d/1FbDuxSaUOrkOubAsJqw1zbSVJCGgxhQau08r9AlbykY/edit?usp=sharing>
{% endembed %}

***

#### Downloading Data from CHORDS

3D-PAWS observations can also be downloaded programmatically from a CHORDS portal using its REST API.

The **3D-PAWS CHORDS Data Downloader** provides a tool for retrieving observations from a CHORDS portal.

{% embed url="<https://github.com/3d-paws/CHORDS_Data_Downloader>" %}

{% hint style="info" %}
For most routine station monitoring, use CHORDS or Grafana directly. The data downloader is useful when observations need to be exported for additional analysis or processing.
{% endhint %}

***

#### Creating Your Own CHORDS Portal

Organizations or projects can also operate their own CHORDS portal for storing and providing access to environmental observations.

A CHORDS portal provides the web server and database infrastructure needed to ingest, store, and serve real-time observations.

This may be useful for organizations that want to:

* manage their own observation network
* maintain a dedicated data portal
* configure instruments and data streams for their project
* provide access to observations through a web interface and API

For instructions on deploying and configuring a CHORDS portal, see the official **CHORDS Getting Started** documentation.

<https://earthcubeprojects-chords.github.io/chords-docs/gettingstarted/>

{% hint style="info" %}
Creating and maintaining a CHORDS portal requires additional system administration beyond the routine use of an existing 3D-PAWS data portal.
{% endhint %}


# Particle / CHORDS Integrations

Guide to sending 3D-PAWS observations from the Particle Cloud to a CHORDS portal using Particle webhooks.

### Overview

Particle-based 3D-PAWS stations transmit observations to the Particle Cloud.

A **Particle webhook** forwards those observations from the Particle Cloud to the CHORDS portal associated with the station or observation network.

The data flow is:

**3D-PAWS Sensors → Particle Data Logger → Particle Cloud → Webhook → CHORDS → Grafana**

The webhook must be configured with information for both the Particle device and the destination CHORDS portal.

***

#### How the Integration Works

When a 3D-PAWS Particle data logger publishes an event, the Particle Cloud receives the event and checks for a matching webhook.

The webhook then sends the observation to the configured CHORDS URL.

For the integration to work correctly:

1. The Particle device must be online and publishing events.
2. A webhook must be configured for the appropriate event.
3. The webhook must contain the correct CHORDS portal information.
4. CHORDS must recognize the API key and instrument ID.
5. The observation must be successfully received by CHORDS.

{% hint style="info" %}
If the Particle device is publishing observations but they are not appearing in CHORDS, the webhook is an important point to check during troubleshooting.
{% endhint %}

***

#### Particle Webhook Training

The training slides below provide a walkthrough of Particle webhooks and their use with 3D-PAWS.

{% embed url="<https://docs.google.com/presentation/d/1JQQpRib1JzjuH940h61ls5MLCOkYerSNbst-YOyfXnM/edit?usp=sharing>" %}
Click the dots icon to enlarge by entering full screen
{% endembed %}

{% hint style="info" %}
Use the presentation controls to open the slides in full screen for easier viewing.
{% endhint %}

***

#### CHORDS Webhook Template

The webhook template must be customized for the Particle device and CHORDS portal being used.

Before creating the webhook, identify the following information:

| Variable        | Description                                                                                                      |
| --------------- | ---------------------------------------------------------------------------------------------------------------- |
| `instrument_id` | CHORDS instrument ID assigned to the station                                                                     |
| `deviceID`      | Particle device ID                                                                                               |
| `name`          | Name used to identify the Particle webhook/device                                                                |
| `key`           | API key for the destination CHORDS portal                                                                        |
| `event`         | Particle event associated with the station configuration, such as `FS` for Full Station or `SG` for Stream Gauge |
| `url`           | URL of the CHORDS portal receiving the observations                                                              |

{% hint style="warning" %}
The values in the template are examples. Replace all station-, device-, and portal-specific values before using the webhook.

In particular, make sure the **CHORDS URL**, **API key**, and **instrument ID** correspond to the destination portal for your observation network.
{% endhint %}

If UCAR/COMET configured the CHORDS portal for your project, contact the project team for the appropriate API key and configuration information.

***

#### Webhook Template

Copy the JSON template below into a plain-text editor and replace the required values with those for your Particle device and CHORDS portal.

{% embed url="<https://docs.google.com/document/d/1-JZLgsLOY9b2fxWdEgkbFyIihc1vPE3IFHjKVfiO9Y0/edit?usp=sharing>" %}

{% hint style="info" %}
Do not modify the observation-variable mappings in the `query` section unless the station firmware or CHORDS configuration requires different variables.
{% endhint %}

***

#### Verify the Integration

After creating the webhook, verify the complete data path.

1. Confirm that the Particle device is online.
2. Confirm that the expected event is being published in the Particle Console.
3. Confirm that the webhook is triggered by the event.
4. Check the webhook response for errors.
5. Open the appropriate CHORDS portal.
6. Confirm that new observations are appearing for the correct instrument.
7. Check that timestamps and sensor variables are updating as expected.

{% hint style="info" %}
Successful publication in the Particle Cloud does not necessarily mean that the observation has reached CHORDS. Verify the observation at the destination portal before considering the integration complete.
{% endhint %}

***

#### If Data Is Not Reaching CHORDS

If Particle events are being published but observations are not appearing in CHORDS, check:

* the webhook is enabled
* the webhook event matches the event published by the device
* the CHORDS `url` is correct
* the `instrument_id` is correct
* the API `key` is correct
* the Particle `deviceID` is correct
* the webhook response for an error from CHORDS

For detailed diagnostic procedures, see **Troubleshooting**.


# Grafana

Guide to using Grafana dashboards to visualize and monitor 3D-PAWS observations.

### Overview

Grafana provides interactive dashboards for viewing 3D-PAWS observations stored in CHORDS.

Grafana can be used to:

* view current station conditions
* explore observations over time
* compare multiple sensor variables
* identify gaps or unusual patterns in station data
* create and customize dashboards for different monitoring needs

***

#### Accessing Grafana

Grafana can be accessed from the **Visualization** link in the CHORDS portal associated with your station or observation network.

1. Open your CHORDS portal.
2. Locate the **Visualization** link.
3. Open Grafana.
4. Select the appropriate dashboard or station.

{% hint style="info" %}
CHORDS portal URLs vary by country or project. Access Grafana through the CHORDS portal used by your observation network.
{% endhint %}

***

#### Working with Dashboards

Grafana dashboards are made up of panels that display observations from one or more sensors.

Depending on the dashboard configuration, panels may display:

* time-series graphs
* current values
* gauges
* tables
* other visualizations

Use the dashboard time controls to explore observations over different time periods.

Grafana dashboards can also be customized to display the measurements and time ranges most useful for a particular project or observation network.

***

#### Grafana Training

The training slides below provide guidance for using Grafana with 3D-PAWS observations.

{% embed url="<https://docs.google.com/presentation/d/1j4ZKrwbDsa-lDLLgxVLLoM20d7KlIMtF6hZ7dyQeNtA/edit?usp=sharing>" %}
Click the dots icon to enlarge by entering full screen
{% endembed %}

{% hint style="info" %}
Use the presentation controls to open the slides in full screen for easier viewing.
{% endhint %}

***

#### Copying a Dashboard

Existing Grafana dashboards can be copied and adapted for another station or monitoring application.

The video below demonstrates how to copy a dashboard.

{% embed url="<https://drive.google.com/file/d/1g4-Jt36rWJz-sFnyKJWIkyA-6jaVy78x/view?usp=sharing>" %}

{% hint style="info" %}
Copying an existing dashboard can be easier than building a new dashboard from the beginning, especially when multiple stations use similar sensor configurations.
{% endhint %}

***

#### Using Grafana to Check Station Data

Grafana provides a quick way to visually inspect station observations and identify potential problems.

When reviewing a dashboard, look for:

* expected observations updating over time
* gaps in the data
* values that remain unexpectedly constant
* abrupt changes or unusual patterns
* differences between related measurements

If observations are missing from Grafana, check whether the data are present in CHORDS before troubleshooting the dashboard.

{% hint style="info" %}
If observations are present in **CHORDS** but not displaying correctly in **Grafana**, investigate the dashboard or data-source configuration.

If observations are also missing from **CHORDS**, troubleshoot the station-to-CHORDS data path instead.
{% endhint %}

→ [**Troubleshooting**](/station-maintenance-and-operations/troubleshooting)

***

#### Creating Custom Dashboards

Grafana dashboards can be customized to display the observations most useful for a particular station, project, or monitoring network.

You can create dashboards that:

* display selected sensor variables
* combine multiple measurements on a single dashboard
* use different visualization types
* show specific time ranges
* organize observations into different panels
* use variables to switch between stations or instruments

If you are new to Grafana, copying an existing 3D-PAWS dashboard is often the easiest place to start. You can then modify the copied dashboard for your station or project.

**Dashboard Tutorials**

The resources below provide additional guidance for creating and customizing Grafana dashboards.

* [**Grafana Docs – Build Your First Dashboard**](https://grafana.com/docs/grafana/latest/getting-started/build-first-dashboard/)\
  Step-by-step guide to create your first dashboard, add panels, and start visualizing real-time data.
* [**Grafana Docs – Panels & Visualizations**](https://grafana.com/docs/grafana/latest/panels-visualizations/)\
  Learn about the various types of panels and visualizations Grafana offers, including customization options.
* [**Grafana YouTube Channel**](https://www.youtube.com/@Grafana)\
  Official Grafana video content, including tutorials, feature guides, and user stories.
* [**Grafana YouTube – Visualizations Tutorial**](https://www.youtube.com/watch?v=yNRnLyVntUw)\
  A great visual tutorial on using and customizing Grafana visualizations.

For additional guidance, see the official **Grafana Dashboard Documentation**.


# Station Maintenance and Operations

Guidance for maintaining 3D-PAWS stations, troubleshooting issues, planning component replacement, and managing station assets over time.

### Overview

After deployment, 3D-PAWS stations require ongoing monitoring, maintenance, and documentation to ensure reliable operation and high-quality data.

This section covers the activities needed to keep a station functioning over time.

***

### Operational Responsibilities

Station operation includes:

* performing routine maintenance and inspections
* monitoring data quality and system performance
* troubleshooting issues as they arise
* planning for component replacement over time
* documenting maintenance activities and site conditions

***

### Pages in This Section

Use the following pages to manage station operations:

* [**Station Maintenance**](/station-maintenance-and-operations/station-maintenance) – routine inspection, cleaning, and system checks
* [**Troubleshooting**](/station-maintenance-and-operations/troubleshooting) – identifying and resolving system and data issues
* [**Sensor Lifecycle Planning**](/station-maintenance-and-operations/sensor-lifecycle-planning) – planning for replacement and long-term maintenance
* [**Asset Management**](/station-maintenance-and-operations/asset-management) – tracking equipment and station components


# Station Maintenance

Routine inspection, cleaning, and system checks to keep 3D-PAWS stations operating reliably and producing high-quality data.

### Overview

Routine maintenance helps ensure that 3D-PAWS stations continue to operate reliably and produce high-quality observations over time.

Maintenance includes:

* inspecting station components
* cleaning sensors and equipment
* checking power and communications
* identifying damage or wear
* documenting maintenance activities
* replacing components when necessary

***

#### Routine Maintenance

During each maintenance visit:

* inspect sensors and mounts for damage
* verify that cables and connections are secure
* clean sensors and the solar panel as needed
* check battery condition and voltage
* ensure the data logger enclosure is sealed and protected from moisture
* inspect the station structure and mounting hardware
* look for corrosion, cable wear, loose hardware, or other signs of deterioration
* remove accumulated dirt, debris, insects, or vegetation

{% hint style="info" %}
Maintenance needs vary by deployment environment. Stations exposed to dust, salt, high humidity, insects, vegetation, or severe weather may require more frequent inspection and cleaning.
{% endhint %}

***

#### Sensor Maintenance

**Rain Gauge**

* remove leaves, dirt, insects, and other debris
* ensure the tipping mechanism moves freely
* verify that the gauge remains level
* inspect the funnel and drainage path for blockage
* check the mounting hardware and cable connection

**Wind Sensors**

* confirm that the anemometer and wind vane rotate freely without binding
* remove debris or obstructions
* inspect for physical damage or wear
* check mounting stability
* inspect cables and connections
* verify that the wind vane remains correctly aligned

**Radiation Shield (Temperature / Humidity / Pressure)**

* clean exterior surfaces if dirty
* ensure ventilation openings are clear
* inspect for insects or nesting
* check mounting hardware
* inspect sensor cables and connections

**Solar Panel**

* remove dust, dirt, leaves, bird droppings, or other material from the panel surface
* inspect the panel for damage
* check mounting hardware
* verify that cables and connections are secure
* check for new vegetation or other objects that may be shading the panel

**Soil Sensors (if installed)**

* confirm good soil contact
* inspect for disturbance or exposure
* check cable integrity
* inspect the installation area for erosion or other changes

***

#### System Checks

Maintenance should include verification that the station is operating correctly.

Check that:

* data transmission is active
* sensor readings are updating
* expected sensors are reporting
* there are no unexpected gaps in observations
* values are not unexpectedly constant or unrealistic
* battery voltage is within the expected operating range
* the solar charging system is operating

{% hint style="info" %}
For Particle-based stations, review **INFO messages** when available. INFO messages can help identify sensor, storage, power, and communications conditions that may require attention.
{% endhint %}

If missing or unusual observations are identified during maintenance, see **Troubleshooting**.

***

#### Lifecycle Planning

Station components will eventually require replacement because of environmental exposure, mechanical wear, battery aging, or changes in sensor performance.

Replacement intervals depend on the component and deployment environment.

→ [**Sensor Lifecycle Planning**](/station-maintenance-and-operations/sensor-lifecycle-planning)

{% hint style="info" %}
Routine cleaning and inspection can extend the useful life of station components, but maintenance does not eliminate long-term sensor aging, mechanical wear, or battery degradation.
{% endhint %}

***

#### Document Maintenance Activities

Record maintenance activities after each station visit.

At minimum, document:

* date of maintenance
* technician or organization
* site conditions
* work performed
* issues observed
* components repaired or replaced
* follow-up actions required

Update station records when components are replaced or the station configuration changes.

→ [**Station Metadata**](/deploying-3d-paws/station-metadata)

→ [**Asset Management**](/station-maintenance-and-operations/asset-management)

{% hint style="info" %}
Consistent maintenance records provide an operational history of the station and can help identify recurring problems and plan future maintenance.
{% endhint %}

***

#### Common Maintenance Issues

| Issue                             | Action                                                |
| --------------------------------- | ----------------------------------------------------- |
| **No data transmission**          | Check power, communications, and data logger status   |
| **Incorrect or unusual readings** | Inspect the sensor, wiring, and installation          |
| **Intermittent data**             | Check cable connections and power stability           |
| **Physical damage**               | Repair or replace affected components                 |
| **Low battery**                   | Check solar input, connections, and battery condition |
| **Debris or contamination**       | Clean and inspect affected instruments                |

For detailed diagnostic procedures, see **Troubleshooting**.

***

#### Instruction Slides for Routine Maintenance

Use the instruction slides below for additional guidance on inspecting, cleaning, and maintaining a 3D-PAWS station.

{% embed url="<https://docs.google.com/presentation/d/1lMNNqnBr8TgxWYTIGRd9mA-_XadPr-9D/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

{% hint style="info" %}
Use the presentation controls to open the slides in full screen for easier viewing.
{% endhint %}


# Troubleshooting

Guide to diagnosing common 3D-PAWS issues with power, connectivity, sensor performance, and data transmission.

### Overview

Troubleshooting helps identify and resolve issues with station operation, data transmission, and sensor performance.

Start with simple checks before moving to more detailed diagnostics.

***

### Quick Checks (2 minutes)

* confirm the station is powered
* verify battery voltage (>3.6V) and solar charging
* check that all cables and connections are secure
* confirm the data logger is operating
* verify network connectivity (cellular / WiFi / LoRa)

***

### Data Issue Patterns

Start by identifying what the data is doing, then use the table below to guide troubleshooting.

| 🔍 Observation                  | Likely Cause                                    | Action                                           |
| ------------------------------- | ----------------------------------------------- | ------------------------------------------------ |
| No data at all                  | Power loss, connectivity issue, logger offline  | Check power, battery, and network connection     |
| Data flatlines (constant value) | Sensor disconnected or stuck                    | Inspect wiring and sensor function               |
| Spikes or erratic values        | Loose connection or electrical noise            | Check cable connections and routing              |
| Temperature too high            | Radiation shield exposed to sun or poor airflow | Check siting and shielding                       |
| Rain recorded with no rainfall  | Debris or tipping bucket issue                  | Inspect and clean rain gauge                     |
| Wind always zero                | Blocked or damaged sensor                       | Check for obstructions or mechanical failure     |
| Battery voltage dropping        | Insufficient solar input or battery degradation | Check solar panel exposure and battery condition |
| Intermittent data gaps          | Poor connectivity or unstable power             | Check network signal and power stability         |

***

### Common Issues

| ❌ Issue                   | ✅ Action                                          |
| ------------------------- | ------------------------------------------------- |
| No data transmission      | Check power, connectivity, and data logger status |
| Incorrect sensor readings | Inspect sensors, wiring, and siting               |
| Intermittent data         | Check cable connections and power stability       |
| Low battery               | Verify solar input and battery condition          |
| No communication          | Check network signal and configuration            |

***

### Sensor-Specific Issues

#### Rain Gauge

* debris blocking tipping mechanism
* not level
* obstruction affecting rainfall

***

#### Wind Sensors

* blocked or restricted rotation
* debris or damage
* incorrect alignment

***

#### Radiation Shield (Temperature / Humidity / Pressure)

* exposure to direct sunlight or shading
* poor airflow
* contamination or dirt

***

#### Soil Sensors (if installed)

* poor soil contact
* disturbed installation
* damaged cable

***

### Troubleshooting Workflow

1. check power
2. check connections
3. verify configuration
4. inspect sensors
5. confirm data transmission

***

### Detailed Troubleshooting

For step-by-step procedures, decision trees, and advanced diagnostics:

→ See [**Full Troubleshooting Guide**](https://docs.google.com/document/d/1kfcIYtb4YQnOfAAVGMCJ7_WaDcN3Dz5EHTTqvWVuV9I/view)

***

### When to Escalate

If issues persist:

* consult the full troubleshooting guide
* review system configuration on [Github](https://github.com/3d-paws/)
* contact project support or technical team

***

### Summary

Most issues can be resolved by checking **power, connections, and sensor placement**.


# Sensor Lifecycle Planning

Guidance for planning sensor replacement, rotation, and long-term maintenance of 3D-PAWS stations.

### Overview

Environmental sensors and mechanical components change over time because of aging, wear, and exposure to field conditions.

Sensor lifecycle planning helps maintain data quality and station reliability by identifying components that should be inspected, verified, or replaced before they cause extended station downtime or measurement problems.

Replacement intervals should be treated as **planning guidance rather than fixed expiration dates**. Actual service life depends on the component, environmental exposure, maintenance history, and observed performance.

***

#### Why Sensor Lifecycle Planning Is Important

Environmental sensors and station components are continuously exposed to conditions such as:

* humidity and condensation
* temperature cycling
* dust and pollution
* salt exposure
* insects and biological contamination
* ultraviolet radiation
* mechanical wear

Routine cleaning and inspection help maintain sensor performance, but they do not prevent long-term aging, drift, or mechanical wear.

Planned replacement allows components to be removed, inspected, cleaned, and verified while reducing the risk of unexpected failure or undetected measurement problems.

***

#### Environmental Exposure

Replacement intervals depend strongly on the conditions at the deployment site.

For planning purposes, 3D-PAWS deployments can be considered **benign** or **harsh** environments.

**Benign Environments**

Typical characteristics include:

* dry or semi-arid climates
* inland locations away from salt spray
* relatively low dust or pollution
* limited fog, dew, or condensation

**Harsh Environments**

Typical characteristics include:

* coastal or marine environments
* tropical or persistently humid climates
* frequent fog, dew, or condensation
* dusty agricultural environments
* polluted environments

Stations in harsh environments may require more frequent inspection, maintenance, and component replacement.

{% hint style="info" %}
These categories are intended for maintenance planning. Local conditions and observed sensor performance should always be considered when determining replacement intervals.
{% endhint %}

***

#### Radiation Shield Sensor Set

The radiation shield typically contains the air temperature, relative humidity, and pressure sensors.

These sensors are commonly replaced together as a set to simplify field maintenance and verification.

| Sensor                                       | Typical Replacement Interval | Notes                                              |
| -------------------------------------------- | ---------------------------- | -------------------------------------------------- |
| **SHT31D (Relative Humidity / Temperature)** | 1–2 years                    | Interval driven primarily by humidity sensor aging |
| **MCP9808 (Temperature)**                    | 1–2 years                    | Rotated with the radiation shield sensor set       |
| **BMP390 (Pressure)**                        | 1–2 years                    | Rotated with the radiation shield sensor set       |

As general planning guidance:

* **Benign environments:** replace the sensor set approximately every **2 years**
* **Harsh environments:** replace the sensor set approximately every **1–1.5 years**

Replacing the sensors together simplifies field operations and allows the complete sensor set to be inspected and verified after removal.

***

#### Wind and Precipitation Sensors

Wind and precipitation instruments contain moving mechanical components and may experience wear over time.

| Instrument     | Typical Replacement Interval | Primary Consideration                |
| -------------- | ---------------------------- | ------------------------------------ |
| **Wind Vane**  | 2–3 years                    | Mechanical bearing wear              |
| **Anemometer** | 2–3 years                    | Wear in rotating components          |
| **Rain Gauge** | 1–2 years                    | Mechanical condition and calibration |

For wind sensors, general planning guidance is:

* **Benign environments:** approximately every **3 years**
* **Harsh environments:** approximately every **1.5–2 years**

Rain gauges should be inspected regularly and periodically verified or recalibrated to ensure accurate precipitation measurements.

{% hint style="info" %}
A component does not necessarily need to remain in service until its planned replacement interval. Replace or remove a sensor earlier if inspection, verification, or station data indicate abnormal performance.
{% endhint %}

***

#### Optional Sensors

Optional environmental sensors may have different service lives depending on their sensing technology and deployment environment.

Follow manufacturer recommendations when available and consider:

* environmental exposure
* observed sensor performance
* calibration or verification requirements
* physical condition
* maintenance history

{% hint style="info" %}
Soil sensors often require time after installation for the surrounding soil to settle and for measurements to stabilize. Initial stabilization should not automatically be interpreted as sensor aging or failure.
{% endhint %}

***

#### Sensor Rotation

Where practical, maintain verified spare sensors or assemblies that can be exchanged during scheduled maintenance visits.

When rotating a sensor:

1. Install a verified replacement sensor or assembly.
2. Record the replacement in the station maintenance and asset records.
3. Return the removed component for inspection, cleaning, and testing.
4. Repair or recalibrate the component if necessary.
5. Return verified components to the spare inventory for future use.

This approach reduces field time and allows sensor evaluation to be performed under controlled conditions.

***

#### Replace Components Earlier When Needed

Planned replacement intervals should not override evidence that a component is failing or degrading.

Consider earlier replacement when:

* observations become unexpectedly noisy or unstable
* measurements show persistent or unexplained bias
* data become intermittent
* mechanical components bind or no longer move freely
* connectors, cables, or housings show significant deterioration
* moisture, corrosion, or contamination affects the component
* verification or calibration indicates unacceptable performance

See **Troubleshooting** when abnormal station behavior is first identified.

***

#### Record Component Changes

Document sensor and component replacements as part of the station's operational history.

Record:

* station ID
* component or sensor
* installation date
* removal date
* reason for replacement
* condition when removed
* verification or calibration results, when applicable
* replacement component information

→ [**Asset Management**](/station-maintenance-and-operations/asset-management)

→ [**Station Metadata**](/deploying-3d-paws/station-metadata)


# Asset Management

Guidance for tracking 3D-PAWS stations, components, maintenance history, and spare parts over the operational life of an observation network.

### Overview

Operating a network of 3D-PAWS stations requires more than maintaining individual stations. Organizations also need a consistent way to track where stations are located, what equipment is installed, when components are replaced, and what spare parts are available.

An asset management system helps maintain this operational history and supports maintenance planning, troubleshooting, and long-term network sustainability.

Asset management systems do not need to be complex. Depending on the size of the network, records may be maintained using:

* spreadsheets
* shared folders
* databases
* dedicated asset management systems

The most important requirement is **consistent record keeping using a unique station ID across all records**.

***

#### Key Elements of an Asset Management System

A practical 3D-PAWS asset management system should include:

1. a station registry
2. maintenance records
3. sensor and component records
4. spare-parts inventory
5. calibration and verification records
6. links to station documentation

Together, these records provide the operational history of the observing network.

***

#### Station Registry

The station registry is the master list of stations in the network.

At minimum, track:

* station ID
* station name
* location
* installation date
* station status
* data logger type
* communications type
* links to station documentation

{% hint style="info" %}
Use the same **station ID** across the station registry, metadata, maintenance records, component records, and data systems. Consistent identifiers make it much easier to connect information about a station over time.
{% endhint %}

Detailed information about site exposure, instrument heights, installation configuration, and other observational metadata should be maintained in the **Station Metadata** record.

→ [**Station Metadata**](/deploying-3d-paws/station-metadata)

***

#### Station Status

Tracking station status provides a quick overview of network condition and helps prioritize maintenance.

Useful status categories may include:

| Status                   | Meaning                                            |
| ------------------------ | -------------------------------------------------- |
| **Active**               | Station is operating normally                      |
| **Offline**              | Station is not currently transmitting or operating |
| **Maintenance Required** | Station is operating but requires attention        |
| **Under Repair**         | Maintenance or repair is in progress               |
| **Decommissioned**       | Station is no longer in service                    |

Organizations may adapt these categories to match their own operational procedures.

***

#### Maintenance Records

Maintain a history of station inspections, service visits, and repairs.

Typical records include:

* service date
* technician or organization
* issues observed
* actions taken
* components repaired or replaced
* follow-up work required

A maintenance history can help identify recurring problems and support troubleshooting and maintenance planning.

→ [**Station Maintenance**](/station-maintenance-and-operations/station-maintenance)

***

#### Sensor and Component Tracking

Sensors and other station components may be replaced several times during the life of a station.

Track significant components such as:

* temperature and humidity sensors
* pressure sensors
* wind sensors
* rain gauges
* optional environmental sensors
* batteries
* data loggers

For each tracked component, useful information may include:

* component type
* manufacturer and model
* serial number or other identifier, when available
* station where installed
* installation date
* removal date
* reason for removal
* condition when removed
* calibration or verification status, when applicable

Recording installation and removal dates supports **Sensor Lifecycle Planning** and preserves the history of changes to the station.

→ [**Sensor Lifecycle Planning**](/station-maintenance-and-operations/sensor-lifecycle-planning)

***

#### Spare-Parts Inventory

Maintain an inventory of components available for maintenance and repair.

Common spare parts may include:

* sensors
* cables and connectors
* batteries
* data loggers
* communications hardware
* mechanical assemblies
* replacement 3D-printed components

For each item, consider tracking:

* component or part
* quantity available
* storage location
* condition
* compatibility or intended station type

Maintaining appropriate spare parts can reduce station downtime when equipment needs to be repaired or replaced.

{% hint style="info" %}
Lifecycle planning can help determine which spare components should be kept available before they are needed in the field.
{% endhint %}

***

#### Calibration and Verification Records

Some instruments require periodic calibration or verification.

Examples include:

* rain gauge calibration
* distance sensor reference measurements
* sensor verification checks

Calibration or verification records should include:

* instrument or component
* date
* method used
* results
* technician or organization
* corrective action, if required

Keep these records linked to the appropriate station and component.

***

#### Station Documentation

Each station should have associated documentation that can be located from the asset management system.

This may include:

* station metadata
* installation records
* site photographs
* maintenance records
* component replacement records
* calibration and verification records

Together, these records provide the operational history of the station.

{% hint style="info" %}
**Asset management and station metadata serve different purposes.**

**Station metadata** describes the observing site, instrument exposure, and station configuration needed to interpret the observations.

**Asset management** tracks the equipment, maintenance history, replacement history, and operational status of the station over time.
{% endhint %}

***

#### Managing a Network Over Time

Review asset records regularly to identify:

* stations requiring maintenance
* components approaching planned replacement
* recurring equipment failures
* shortages of critical spare parts
* calibration or verification needs
* stations with incomplete records

Keeping these records current makes it easier to plan maintenance visits, prepare replacement equipment, and manage the observation network over the long term.


# Other 3D-PAWS Resources

Additional manuals, reference materials, training, community resources, and field tools for building, deploying, and maintaining 3D-PAWS stations.

### Overview

Use this section to find supporting resources that complement the procedures and guidance provided throughout the 3D-PAWS manual.

***

#### Manuals and Reference Materials

**Current 3D-PAWS Manual**

Download a PDF copy of the current 3D-PAWS manual for offline use.

→ [**Current Full Manual (PDF)**](https://drive.google.com/file/d/1LFGEavYDBucSGU28-EkhmXPjH0kIDs9i/view)

**Previous Manual Versions**

Earlier versions of the 3D-PAWS manual are available for reference.

→ [**Previous Manual Versions**](/other-3d-paws-resources/previous-manual-versions)

{% hint style="info" %}
Use the current online manual for the most up-to-date 3D-PAWS procedures and recommendations. Earlier manuals may describe components, wiring, firmware, or procedures that are no longer current.
{% endhint %}

**Sensor Datasheets**

Manufacturer datasheets provide detailed specifications, electrical characteristics, and technical information for sensors used in 3D-PAWS.

→ [**Sensor Datasheets**](/other-3d-paws-resources/sensor-datasheets)

**Materials and Tools**

Use the Materials and Tools spreadsheet to identify the components, hardware, sensors, and tools required for a 3D-PAWS build.

→ [**Materials and Tools**](/building-3d-paws/getting-started/materials-and-tools)

#### Training and Learning

**COMET Instrumentation Course**

The COMET Instrumentation curriculum provides additional training on meteorological instruments, measurements, and observing practices.

→ [**COMET Instrumentation Course**](https://www.meted.ucar.edu/education_training/course/58)

**3D-PAWS YouTube**

Video resources include build demonstrations, training material, and other 3D-PAWS guidance.

→ [**3D-PAWS Youtube**](https://www.youtube.com/channel/UCaxlD_Ylp3ooI8ej8ACmJDg)

***

#### Community and Support

**3D-PAWS Forum**

Use the 3D-PAWS Forum to ask questions, share experiences, and discuss 3D-PAWS systems with the community.

→ [**3D-PAWS Forum**](https://3dpaws.discourse.group/)

***

#### Additional Resources in This Section

* **3D-PAWS Station Variants** – specialized station configurations for different monitoring applications


# 3D-PAWS Station Variants

Overview of specialized 3D-PAWS station configurations designed for different monitoring and deployment needs.

### Overview

In addition to the standard 3D-PAWS configuration, several station variants are available for applications that prioritize specific measurements, simplified deployment, or rapid mobility.

These variants use the same general 3D-PAWS design philosophy while modifying the sensor suite, mounting system, or communications configuration for a particular use case.

***

#### FEWS NET Station

The **Famine Early Warning Systems Network (FEWS NET) station** is a simplified 3D-PAWS configuration designed to support rainfall and temperature monitoring for drought and food-security applications.

**Key Features**

* two rain gauges for redundancy and comparison
* multiple temperature measurements
* relative humidity measurement
* simplified sensor configuration
* reduced assembly and installation complexity
* no wind sensors
* no light or solar radiation sensor

The dual rain gauge configuration allows precipitation measurements to be cross-checked and can help identify problems with an individual gauge.

This configuration reduces the number of instruments that must be assembled, installed, and maintained while retaining the measurements most important for FEWS NET applications.

{% hint style="info" %}
The FEWS NET station still uses a **radiation shield** for temperature and relative humidity measurements. The omitted instrument is the separate light or solar-radiation sensor, not the radiation shield.
{% endhint %}

{% embed url="<https://docs.google.com/presentation/d/1MyYhBzKAJBn9qHZrckqOTpJipungMzpG/view?usp=sharing>" %}

***

#### Upgraded FEWS NET Station

The **Upgraded FEWS NET station** builds on the rainfall-focused FEWS NET configuration by adding wind measurements.

This configuration provides:

* two rain gauges
* temperature measurements
* relative humidity
* wind speed
* wind direction

The upgraded configuration may be appropriate when an existing FEWS NET station needs additional meteorological measurements without being converted to the full standard 3D-PAWS configuration.

{% embed url="<https://docs.google.com/presentation/d/1nPxa-daAdosGXO0brknbfZohOVw6EHS4/view?slide=id.p1#slide=id.p1>" %}

***

#### Rapid Deployment 3D-PAWS

The **Rapid Deployment 3D-PAWS (RD3D-PAWS)** is designed for temporary or mobile monitoring where a station may need to be installed, relocated, or removed quickly.

Instead of a fixed post, the station is mounted on a folding tripod. Instruments are attached to pre-assembled mounting arms with the required cables and connectors already in place.

The central harness and data logger remain attached to the tripod during transport, reducing the amount of assembly required at the deployment site.

**Key Features**

* folding tripod mounting system
* pre-assembled instrument arms
* prewired central harness
* rapid setup and removal
* portable configuration
* suitable for temporary or emergency monitoring

On-site assembly can typically be completed in **less than 10 minutes** when the system has been properly pre-assembled and prepared for deployment. :contentReference\[oaicite:2]{index=2}

{% embed url="<https://docs.google.com/presentation/d/1mZD6lToqhRbtigm8eCrbrtb4XMO8bc3D/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

***

#### Choosing a Station Configuration

Select the station configuration based on the measurements required, deployment environment, available infrastructure, and operational needs.

| Configuration                 | Primary Use                                          |
| ----------------------------- | ---------------------------------------------------- |
| **Standard 3D-PAWS**          | General-purpose weather and environmental monitoring |
| **FEWS NET Station**          | Rainfall- and temperature-focused monitoring         |
| **Upgraded FEWS NET Station** | FEWS NET monitoring with added wind measurements     |
| **Rapid Deployment 3D-PAWS**  | Temporary, mobile, or rapidly deployable monitoring  |

{% hint style="info" %}
Station variants may require different firmware, wiring, or assembly procedures. Use the documentation associated with the specific configuration being deployed.
{% endhint %}


# Sensor Datasheets

Reference PDFs for 3D-PAWS sensors used in building, wiring, testing, and troubleshooting.

Use these datasheets when building, wiring, or troubleshooting 3D-PAWS sensors and modules.

All links open PDF files in Google Drive.

* [SS451A Hall Effect Sensor](https://drive.google.com/file/d/11g7WHNxx8yAw96QL7NoBcTuqBucDBsyk/view?usp=sharing) - Rain Gauge and Anemometer
* [BMP390](https://drive.google.com/file/d/1SPz26aSSjAcI60IiRl2aWFNGYPNsM4U1/view?usp=sharing) - Temperature and Pressure
* [SHT31D](https://drive.google.com/file/d/16DI1sN1-oBiDy-r1EkRpwLqHehM3LIvt/view?usp=sharing) - Temperature and Relative Humidity
* [MCP9808](https://drive.google.com/file/d/1RvLQRoUSQnQXanRsuRBg3e4OvptU6nNu/view?usp=sharing) - Temperature
* [AS5600](https://drive.google.com/file/d/1f8m0zBGUlcEmwGa42xqODvVKy_ajvcer/view?usp=sharing) - Wind Vane
* [HRXL-MaxSonar-WR](https://drive.google.com/file/d/1s45q6CAMLHU-h02uSoY4lR5ZYnYuU4Ag/view?usp=sharing) - Stream, Storm Surge, and Snow Height
* [PM-WCS-3-I2C](https://drive.google.com/file/d/1Z7gYBLdm5Mjj0HUhAVq8sTMEBgt0ySFo/view?usp=sharing) - Soil Moisture and Temperature
* [PMSA003I](https://drive.google.com/file/d/1IrXs_CaOnHjx0iMXjq4KyVnDOzUqwuHC/view?usp=sharing) - PM 2.5 Air Quality


# 3D-Printer Maintenance

Maintenance checklist, official Bambu Lab references, and care tips for reliable 3D-PAWS part printing.

For full maintenance procedures, part diagrams, and step-by-step instructions, please refer to the **official Bambu Lab maintenance guide**:

**Official Bambu Lab P1 Series Maintenance Manual**\
<https://wiki.bambulab.com/en/p1/maintenance/p1p-maintenance>

For more information about the printer or troubleshooting steps refer to:\
<https://wiki.bambulab.com/en/p1>

***

### Monthly Maintenance Checklist

The table below summarises the core maintenance tasks 3D-PAWS builders should perform **once per month** (or \~80–120 print hours), especially when printing ASA:

| Area                          | Task                               | Purpose                                          |
| ----------------------------- | ---------------------------------- | ------------------------------------------------ |
| Build Plate (Textured PEI)    | Clean with warm water + mild soap  | Remove oils & contaminants for reliable adhesion |
| X/Y/Z Motion System           | Wipe carbon & linear rods          | Remove dust & filament debris                    |
| Z-Axis Lead Screws            | Clean & lightly grease             | Smooth vertical motion                           |
| Extruder & Filament Path      | Blow out dust; inspect PTFE/feeder | Prevent jams & inconsistent extrusion            |
| Filament Cutter (if equipped) | Inspect/replace blade              | Ensure clean filament feeding                    |
| Fans & Filters                | Clear dust; replace carbon filter  | Maintain airflow & cooling                       |
| Calibration                   | First-layer test; bed leveling     | Confirm consistent prints                        |
| Firmware                      | Update via Bambu Studio            | Ensure latest stability improvements             |
| Filament Storage              | Check desiccants; dry if needed    | Prevent moisture issues (critical for ASA)       |

***

### Maintenance Video

{% embed url="<https://www.youtube.com/watch?v=CxubmTN1Srs>" %}

***

### Notes & Tips

* **Build Plate Cleaning**: Soap + water is preferred for textured PEI; alcohol can be used for residue as needed.
* **Motion Rods**: Do *not* grease carbon rods — lubricant attracts dust and accelerates wear.
* **ASA Printing**: Always store ASA dry and print with the enclosure closed for best layer adhesion and minimized warping.


# Manual Translations

Translated versions of the 3D-PAWS manual.


# French

All 3D-PAWS assembly and operations manuals translated into French.

### Rain Gauge

{% embed url="<https://docs.google.com/presentation/d/1S3xbbDg2PC1Y3QDQoDLdNnabtDEkHmqs/view>" %}

{% embed url="<https://docs.google.com/presentation/d/1bIewSWAsNlPqTZjhNYexblmlARULa2zh/view>" %}

[**Rain Gauge Calibration Spreadsheet**](https://docs.google.com/spreadsheets/d/1xiSsWXoyMc4v-e0GQSFJM6cbOwzDT6Qv/view)

{% embed url="<https://docs.google.com/presentation/d/1EWM6ajWBASXyl0H39KV18cVvxzUu99Tz/view>" %}

### Radiation Shield

{% embed url="<https://docs.google.com/presentation/d/1SlQKNuDJYJ4FnltKoQtqMYnJHyEZXOLg/edit?ouid=102244773211795243299&rtpof=true&sd=true&usp=sharing>" %}

{% embed url="<https://docs.google.com/presentation/d/16HUNDX7imnZftj9_vqqTbapOQBnKWK2o/view?slide=id.p1#slide=id.p1>" %}

### Black Globe

{% embed url="<https://docs.google.com/presentation/d/1giKqfUCzN3hsRJT-ORA8LJlFzZ8YnzdZ/view>" %}

### Testing the Instruments

{% embed url="<https://docs.google.com/presentation/d/1MYO9KKb0M_2MSDaONykiWXmWhtkjALnB/view>" %}

### Solar Panel

{% embed url="<https://docs.google.com/presentation/d/1U3c4l8LGYbVsMHu1ZHS6Waw2g2kBGtTd/view>" %}

### Data Logger

{% embed url="<https://docs.google.com/presentation/d/1EkTbFbYbL71ss5GQy4bMPTrc_1iHxRGZ/view>" %}

### Site Selection

{% embed url="<https://docs.google.com/presentation/d/1-LqWLcsFzOIvkvFNomEERLl_orAvjbhK/view?slide=id.p1#slide=id.p1>" %}

### Station Assembly and Maintenance

{% embed url="<https://docs.google.com/presentation/d/10ikEqwgS46reC5SHBMAmkYWWokyXw6B3/view>" %}

{% embed url="<https://docs.google.com/presentation/d/10cnhliIMGFarGxvkWgIWu13xJRIXWZLo/view>" %}

### Accessing the Data

{% embed url="<https://docs.google.com/presentation/d/1yefdmhTp8PyCC79M7DToegeFfBWKhON-/view?slide=id.p1#slide=id.p1>" %}

{% embed url="<https://docs.google.com/presentation/d/1PD5Sgz1bhtJ9KrDNzWQ3gqyOQClM6KVE/view>" %}

{% embed url="<https://docs.google.com/presentation/d/1FvkaB1jfbUISueaxV-nEgH3m_DV5OYhL/view>" %}

### [Full .pdf Version](https://drive.google.com/file/d/14CO-FkLq5uWcdKLSYwNXtcJ-gFQ_cxYP/view?usp=sharing)

### [System Cost](https://docs.google.com/spreadsheets/d/1a0QzEBixcHUBG6jSVOQPB9dM_WMdFf2D/edit?usp=drive_link\&ouid=102244773211795243299\&rtpof=true\&sd=true)


# Previous Manual Versions

Archived 3D-PAWS manuals for older station designs, cable standards, and legacy build references.

Use these archived manuals for reference when working with older 3D-PAWS designs and cable standards.

Available versions:

* [3D-PAWS Manual 2024 (Light Sensor)](https://drive.google.com/file/d/1PaLJj9IL36OOWEJXDKFe7JcrSVSFiKYv/view?usp=sharing)
* [3D-PAWS Manual 2022 (Qwiic cables)](https://drive.google.com/file/d/1BO_cd7vLqdmcS3in6NH8YLqrF26Fl_cI/view?usp=drive_link)
* [3D-PAWS Manual 2020](https://drive.google.com/file/d/1AvuykLYOoLGlMKjI5hs70aMUwuiKobYE/view?usp=sharing)